Advanced Telerobotics Research Lab
Department of Computer Science, Kent State University
Department of Computer Science, Kent State University
Hands-on workshop
Teach a robot your dance
Motion retargeting and robot learning. A phone video of someone dancing becomes 3D human motion, gets retargeted to the Booster K1 humanoid, trained with reinforcement learning in simulation, and runs on the real robot.
- Date
- Saturday, October 24, 2026
- Time
- 10:00 AM – 2:00 PM
- Place
- MSB 228, Kent State
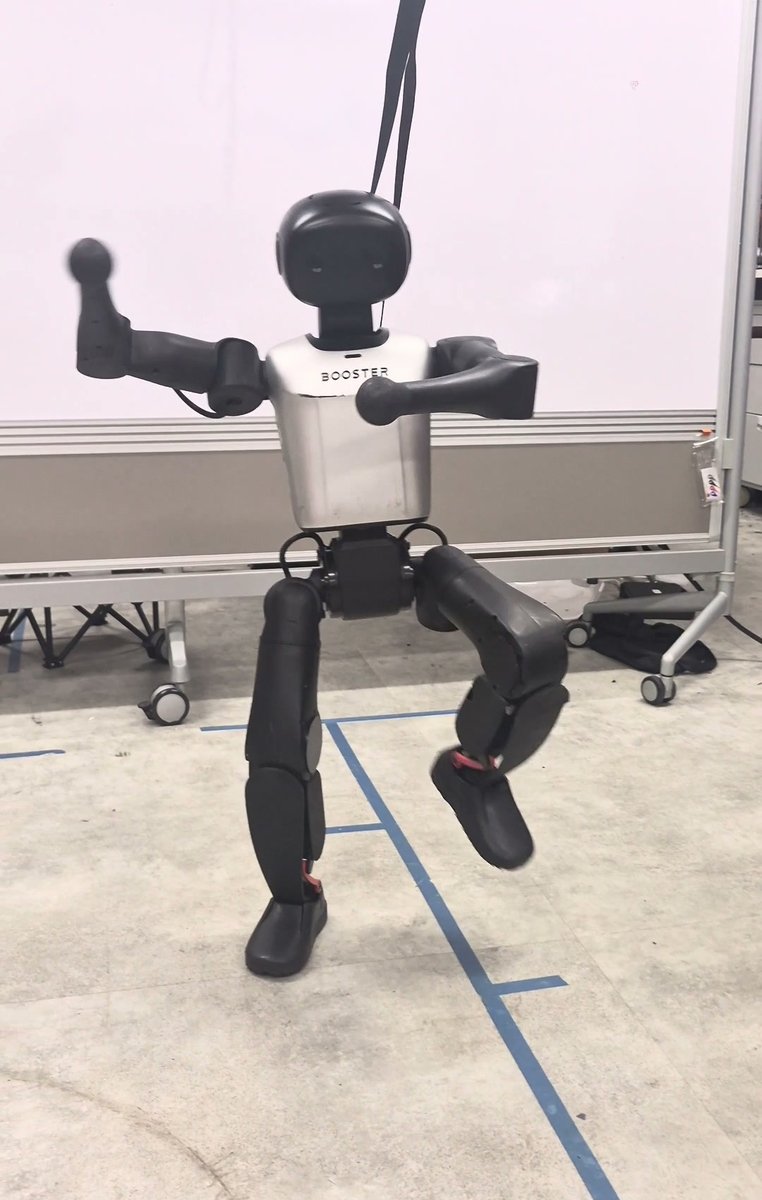 Real robot
How it works
From video to robot
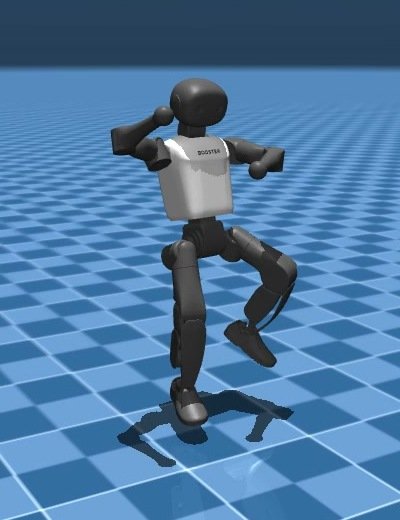
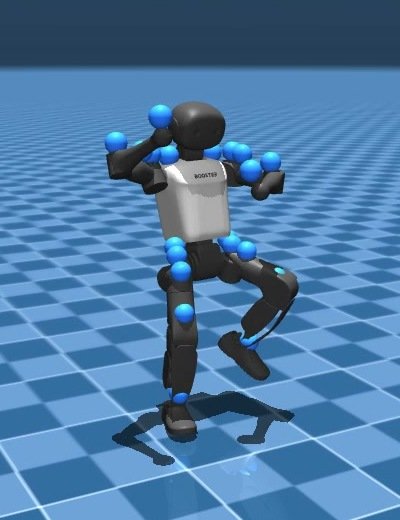
-
01
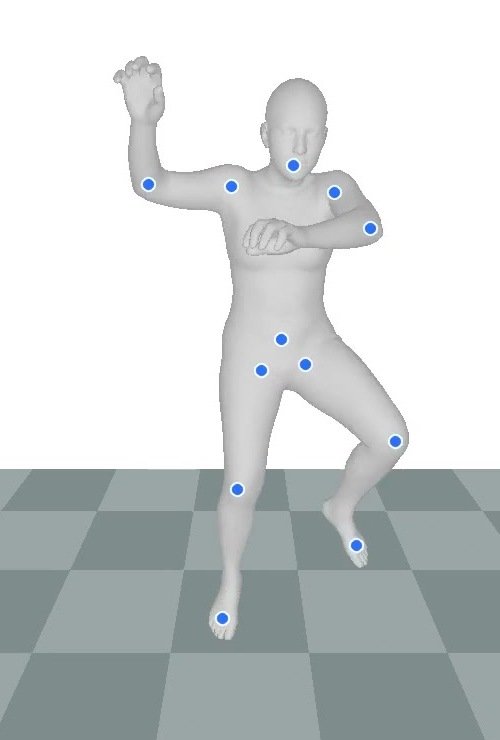
Motion capture
Your video becomes a 3D body moving in space.
-
02
Retargeting
The human motion is mapped onto the robot's joints and proportions.
-
03
Training in simulation
Reinforcement learning teaches the robot to follow the motion without falling.
-
04
Sim-to-real
The trained policy runs on the real K1.
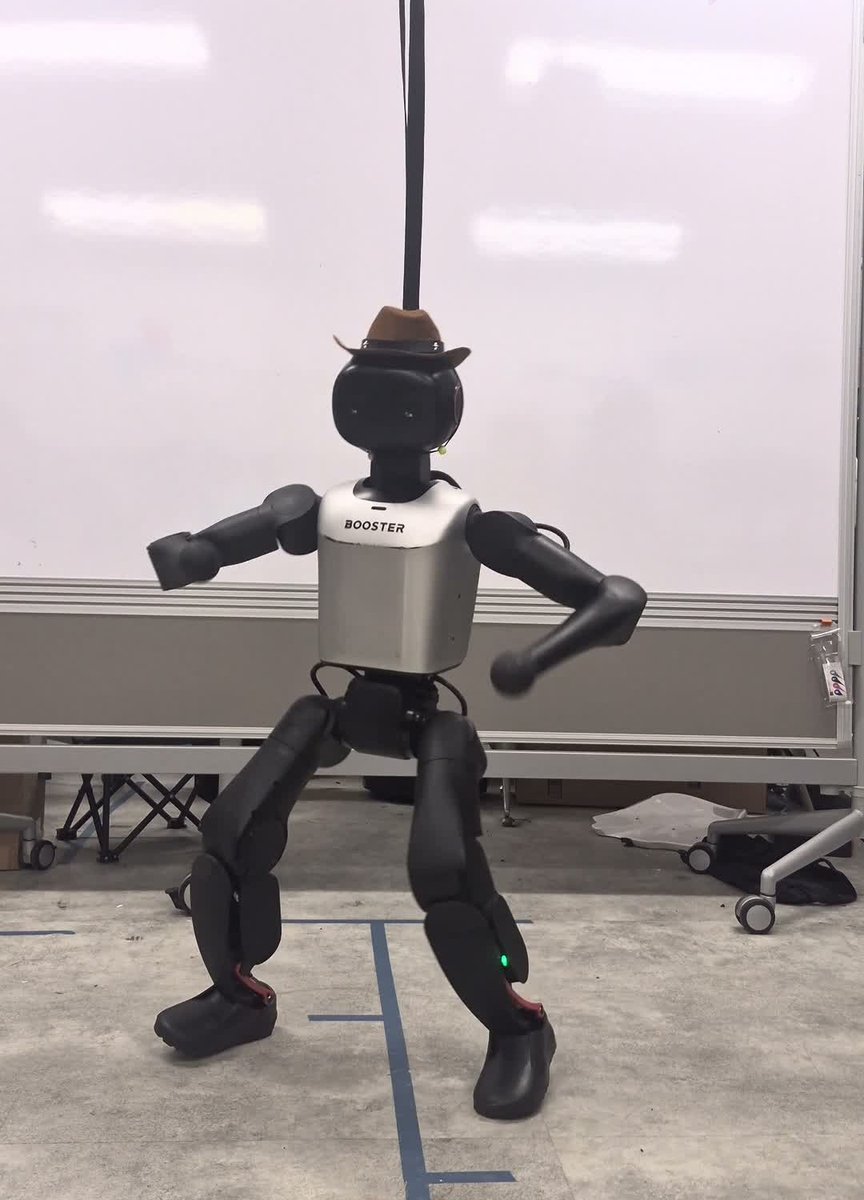
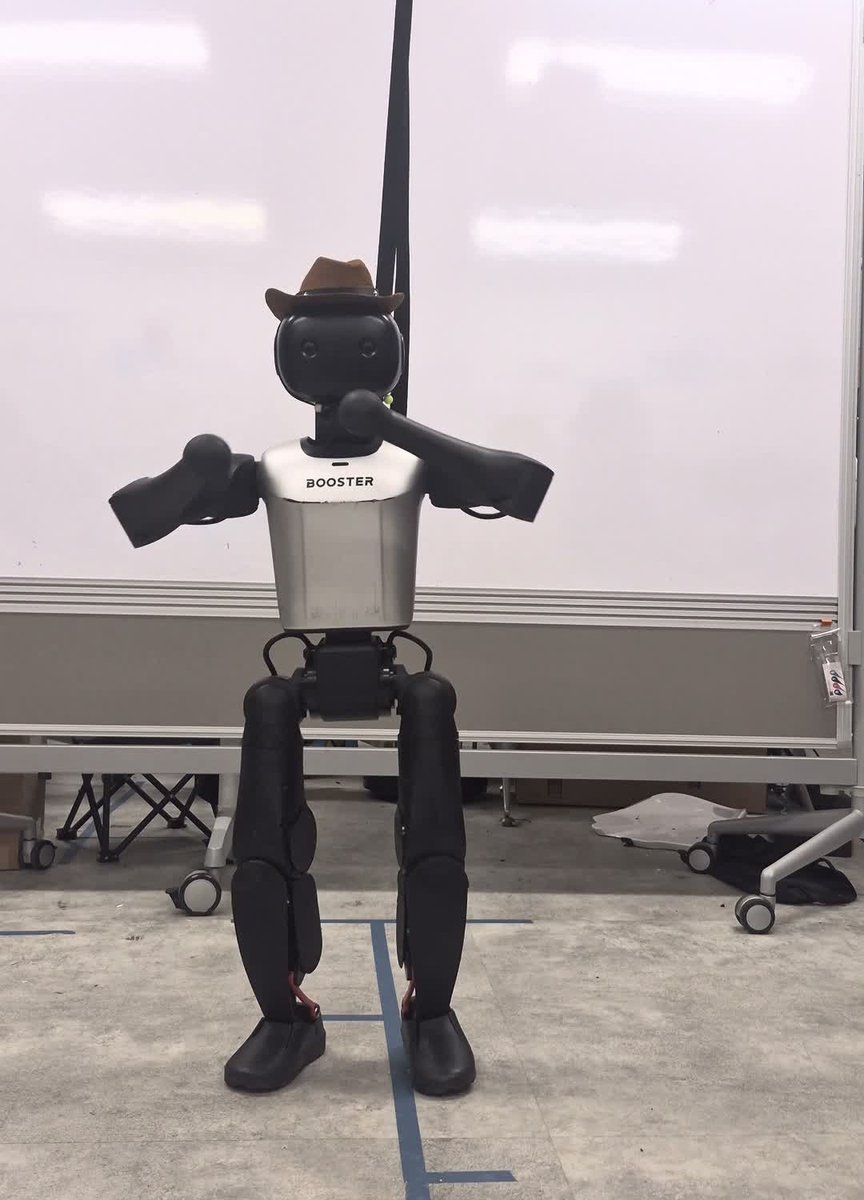
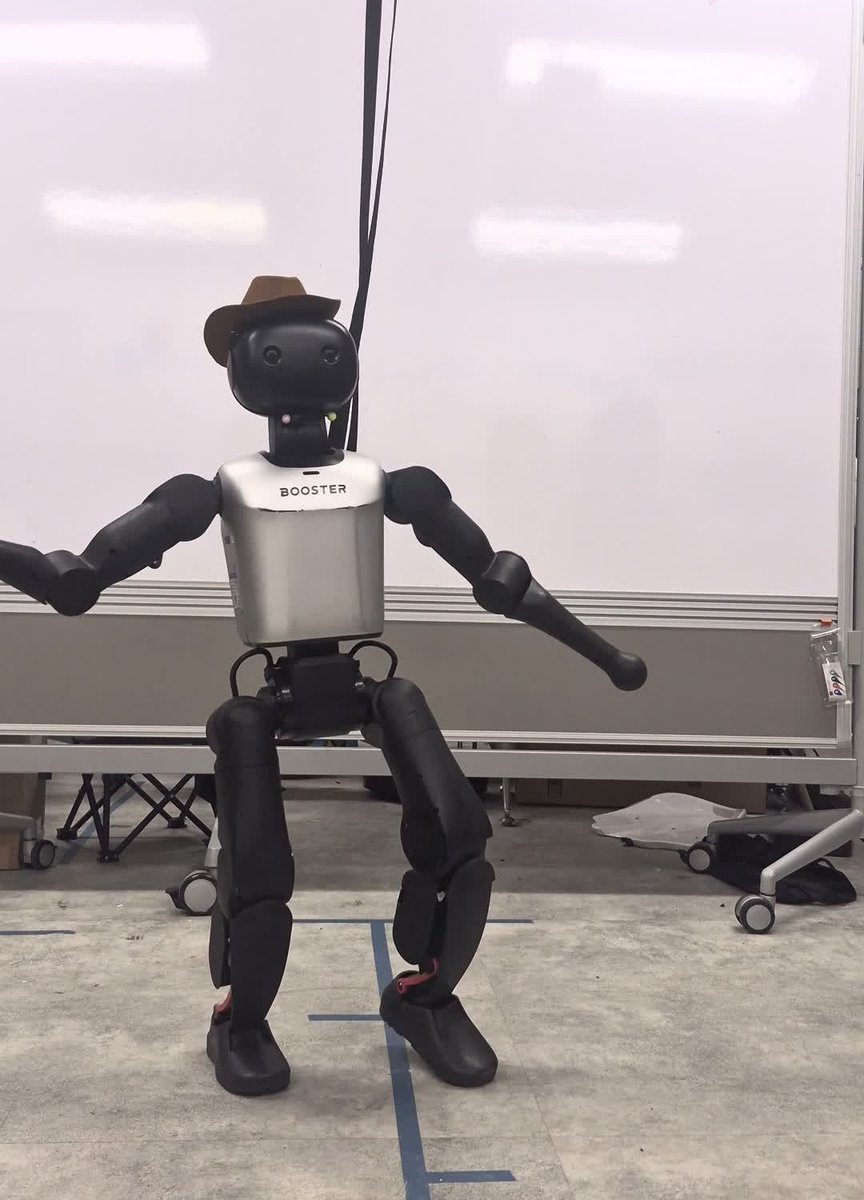
More dances on the real K1.
Tools: GVHMR (video to 3D motion), GMR (retargeting), MuJoCo and mjlab (simulation and training).
What to bring
- A laptop.
- A short video of yourself dancing is nice to have, but optional.
Sign-up
Sign-up form coming soon — just show up.