Summary
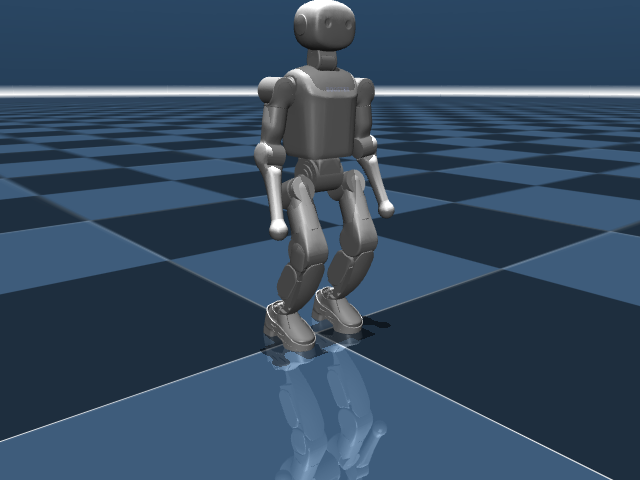
The K1 walking policies are trained barefoot, and in the 50 mm heels they get shaky. The sole is tilted and lower, and every foot is 350 g heavier. I put the shoes into the sim and fine-tuned two policies in them: the normal walk and the loco-teleop one, where the legs walk and the arms are free.
How
- The shoe mesh is the foot collision now, and its weight goes into the foot.
- The reference motions get +15.6° on the ankles and +58.5 mm on the root, so the shoe sole is flat where the bare foot was.
- Warm start from the barefoot checkpoints. A few hundred iterations are enough, from scratch it takes ~4000.
- On deploy the start pose gets the same ankle offset, otherwise the robot starts tipped forward.
Results
All in sim so far.
| barefoot policy | fine-tuned in heels | |
|---|---|---|
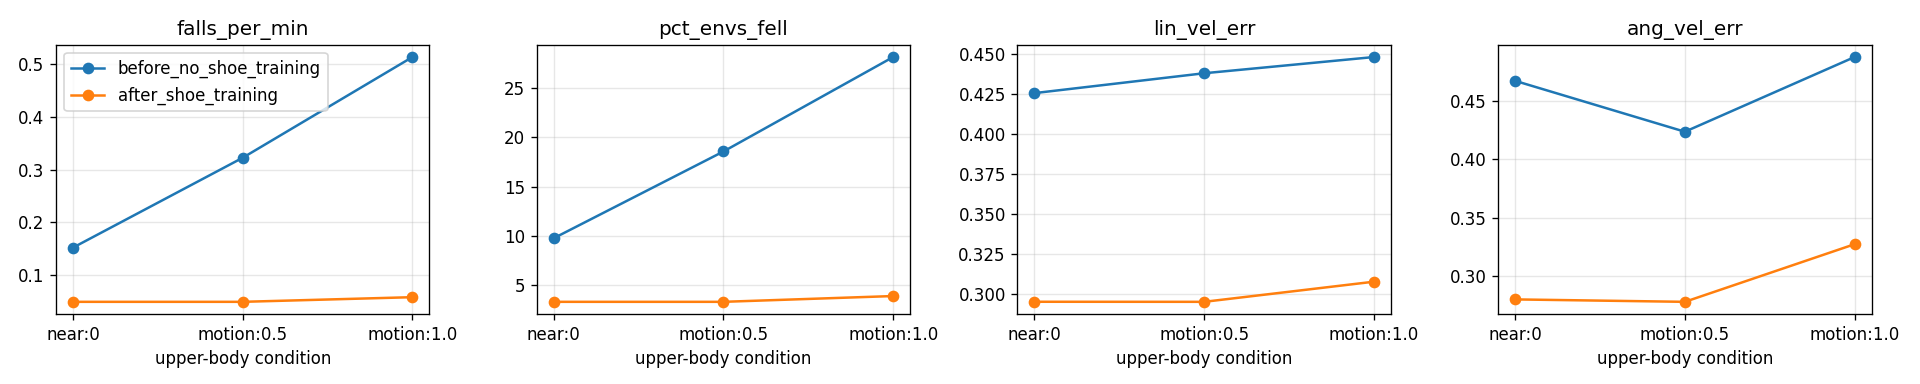
| Loco-teleop, arms moving, envs that fell | 28% | 3.9% |
| Loco-teleop, velocity error | 0.45 | 0.31 |
| Normal walk, standing in MuJoCo | drifts 1.4 m | stands still |
| Normal walk, 0.5 / 1.0 m/s command | 0.50 / 0.95 m/s |