kyry.me/projects
Projects
Learned locomotion on the Booster K1, Unitree G1 and Microduck: gaits from video, adversarial motion priors, whole-body control and footwear. Also social HRI on Pepper and a study of vision-language models. Each project page has its papers and media.
From a monocular runway video to a catwalk gait on the Booster K1.
A runway walk for the Booster K1 learned with adversarial motion priors.
Our Ghost Trial 04 entry. A G1 walks the runway, turns, poses and walks back, by fine-tuning SONIC.
- P-04K1 Heel Shoes
3D-printed heel shoes for the Booster K1.
- P-05K1 Heel Walking
Getting the K1 walking policies to walk in the 50 mm heels. Sim for now.
- P-06K1 Loco-Teleop
A walking policy for the Booster K1 that drives only the legs, so the arms and head stay free for teleoperation.
- P-07K1 Cartwheel
Teaching the Booster K1 a cartwheel from a video. It works in simulation; on the robot it still falls.
Faster running gaits for Pollen Robotics' Microduck on three simulated race courses, fine-tuned with PPO and chosen by the Arena's five-seed score. #1 on the roller sprint leaderboard.
Other research
- P-08Mi-RoL
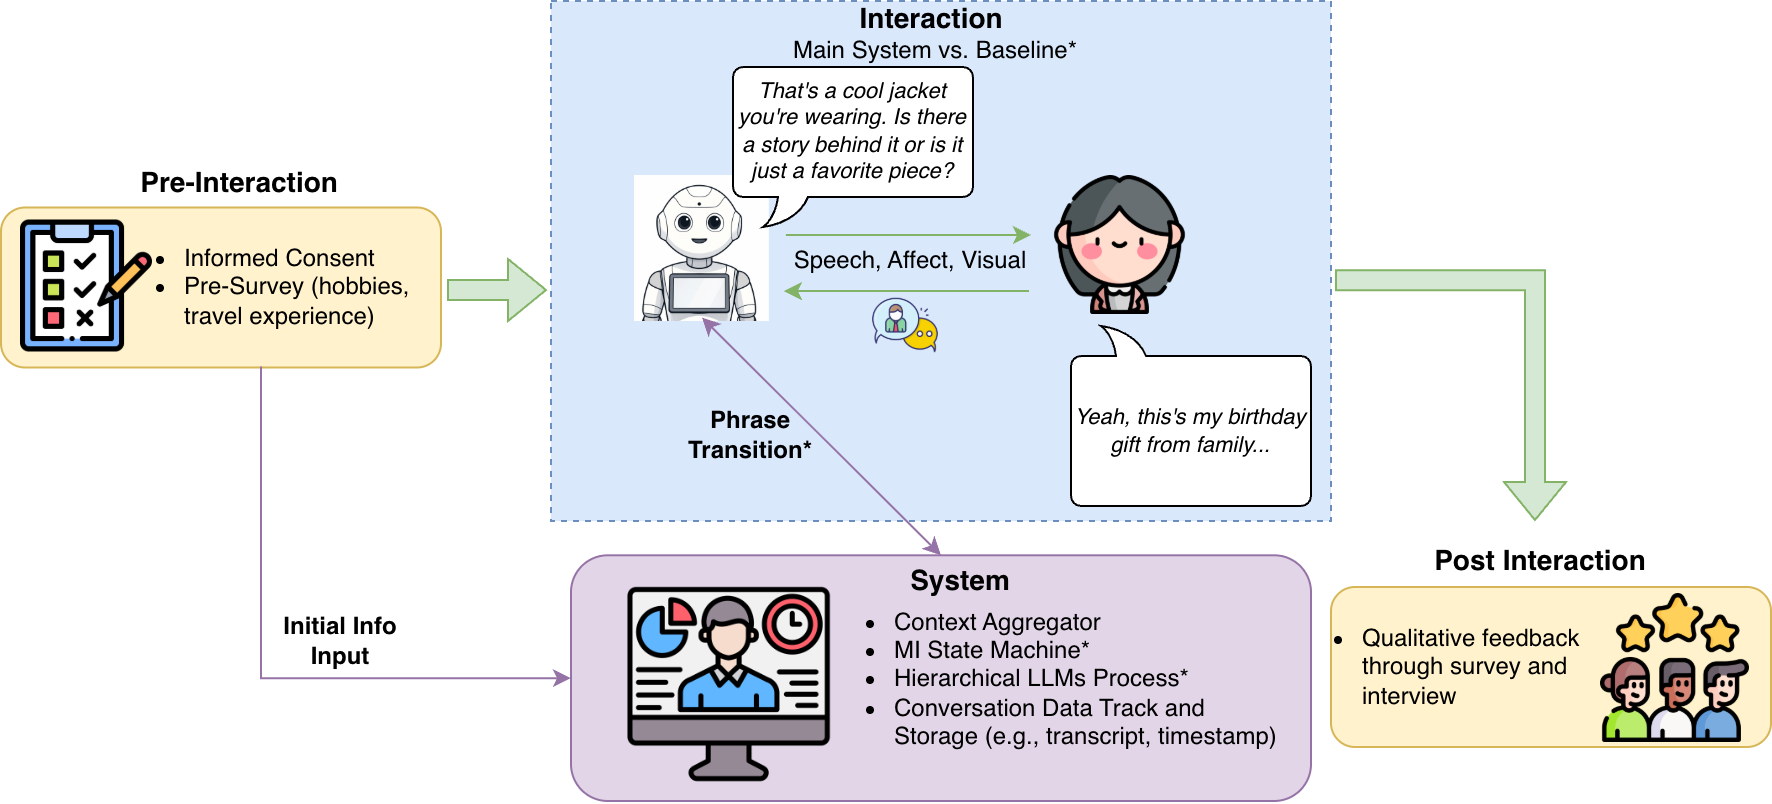
A multi-tier LLM framework for empathetic conversation on the Pepper robot, grounded in Motivational Interviewing. Tested in a 40-participant study.
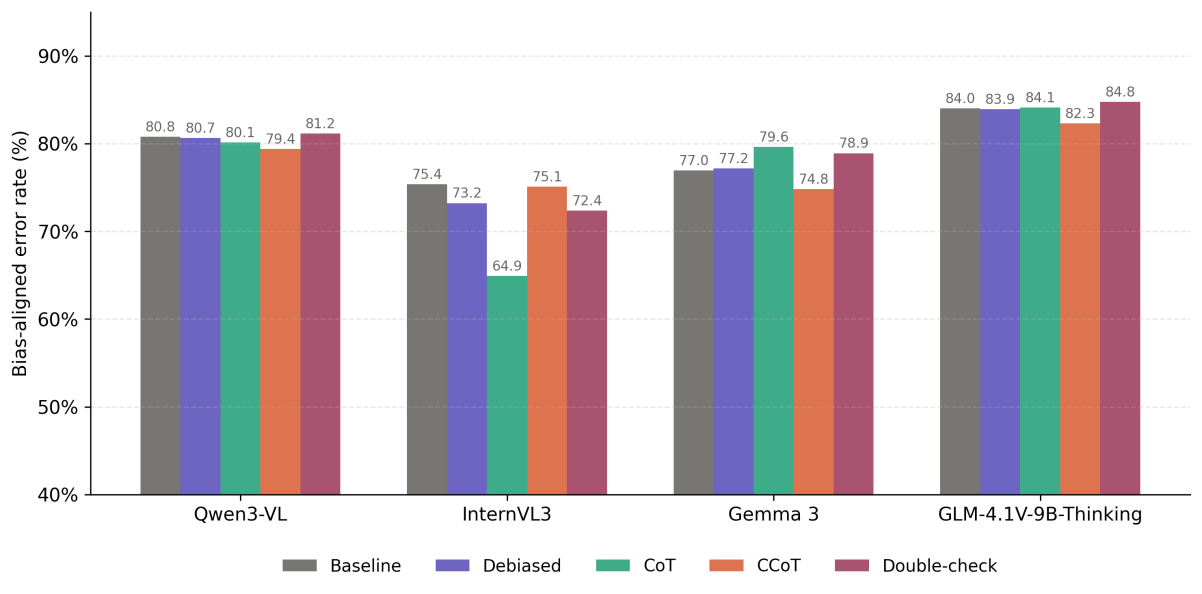
Can structured prompting overcome knowledge bias in vision-language models? Four open-source VLMs, five prompting strategies, the VLMBias benchmark.
Coming soon
Reproducing "Chasing Autonomy: Dynamic Retargeting and Control Guided RL for Performant and Controllable Humanoid Running" and applying it to catwalk walking.
Retargeting NVIDIA's GEAR SONIC whole-body controller to the Booster K1.
- P-12Shoes and impact
How different shoes change the impacts a humanoid takes across different kinds of motion.