Summary
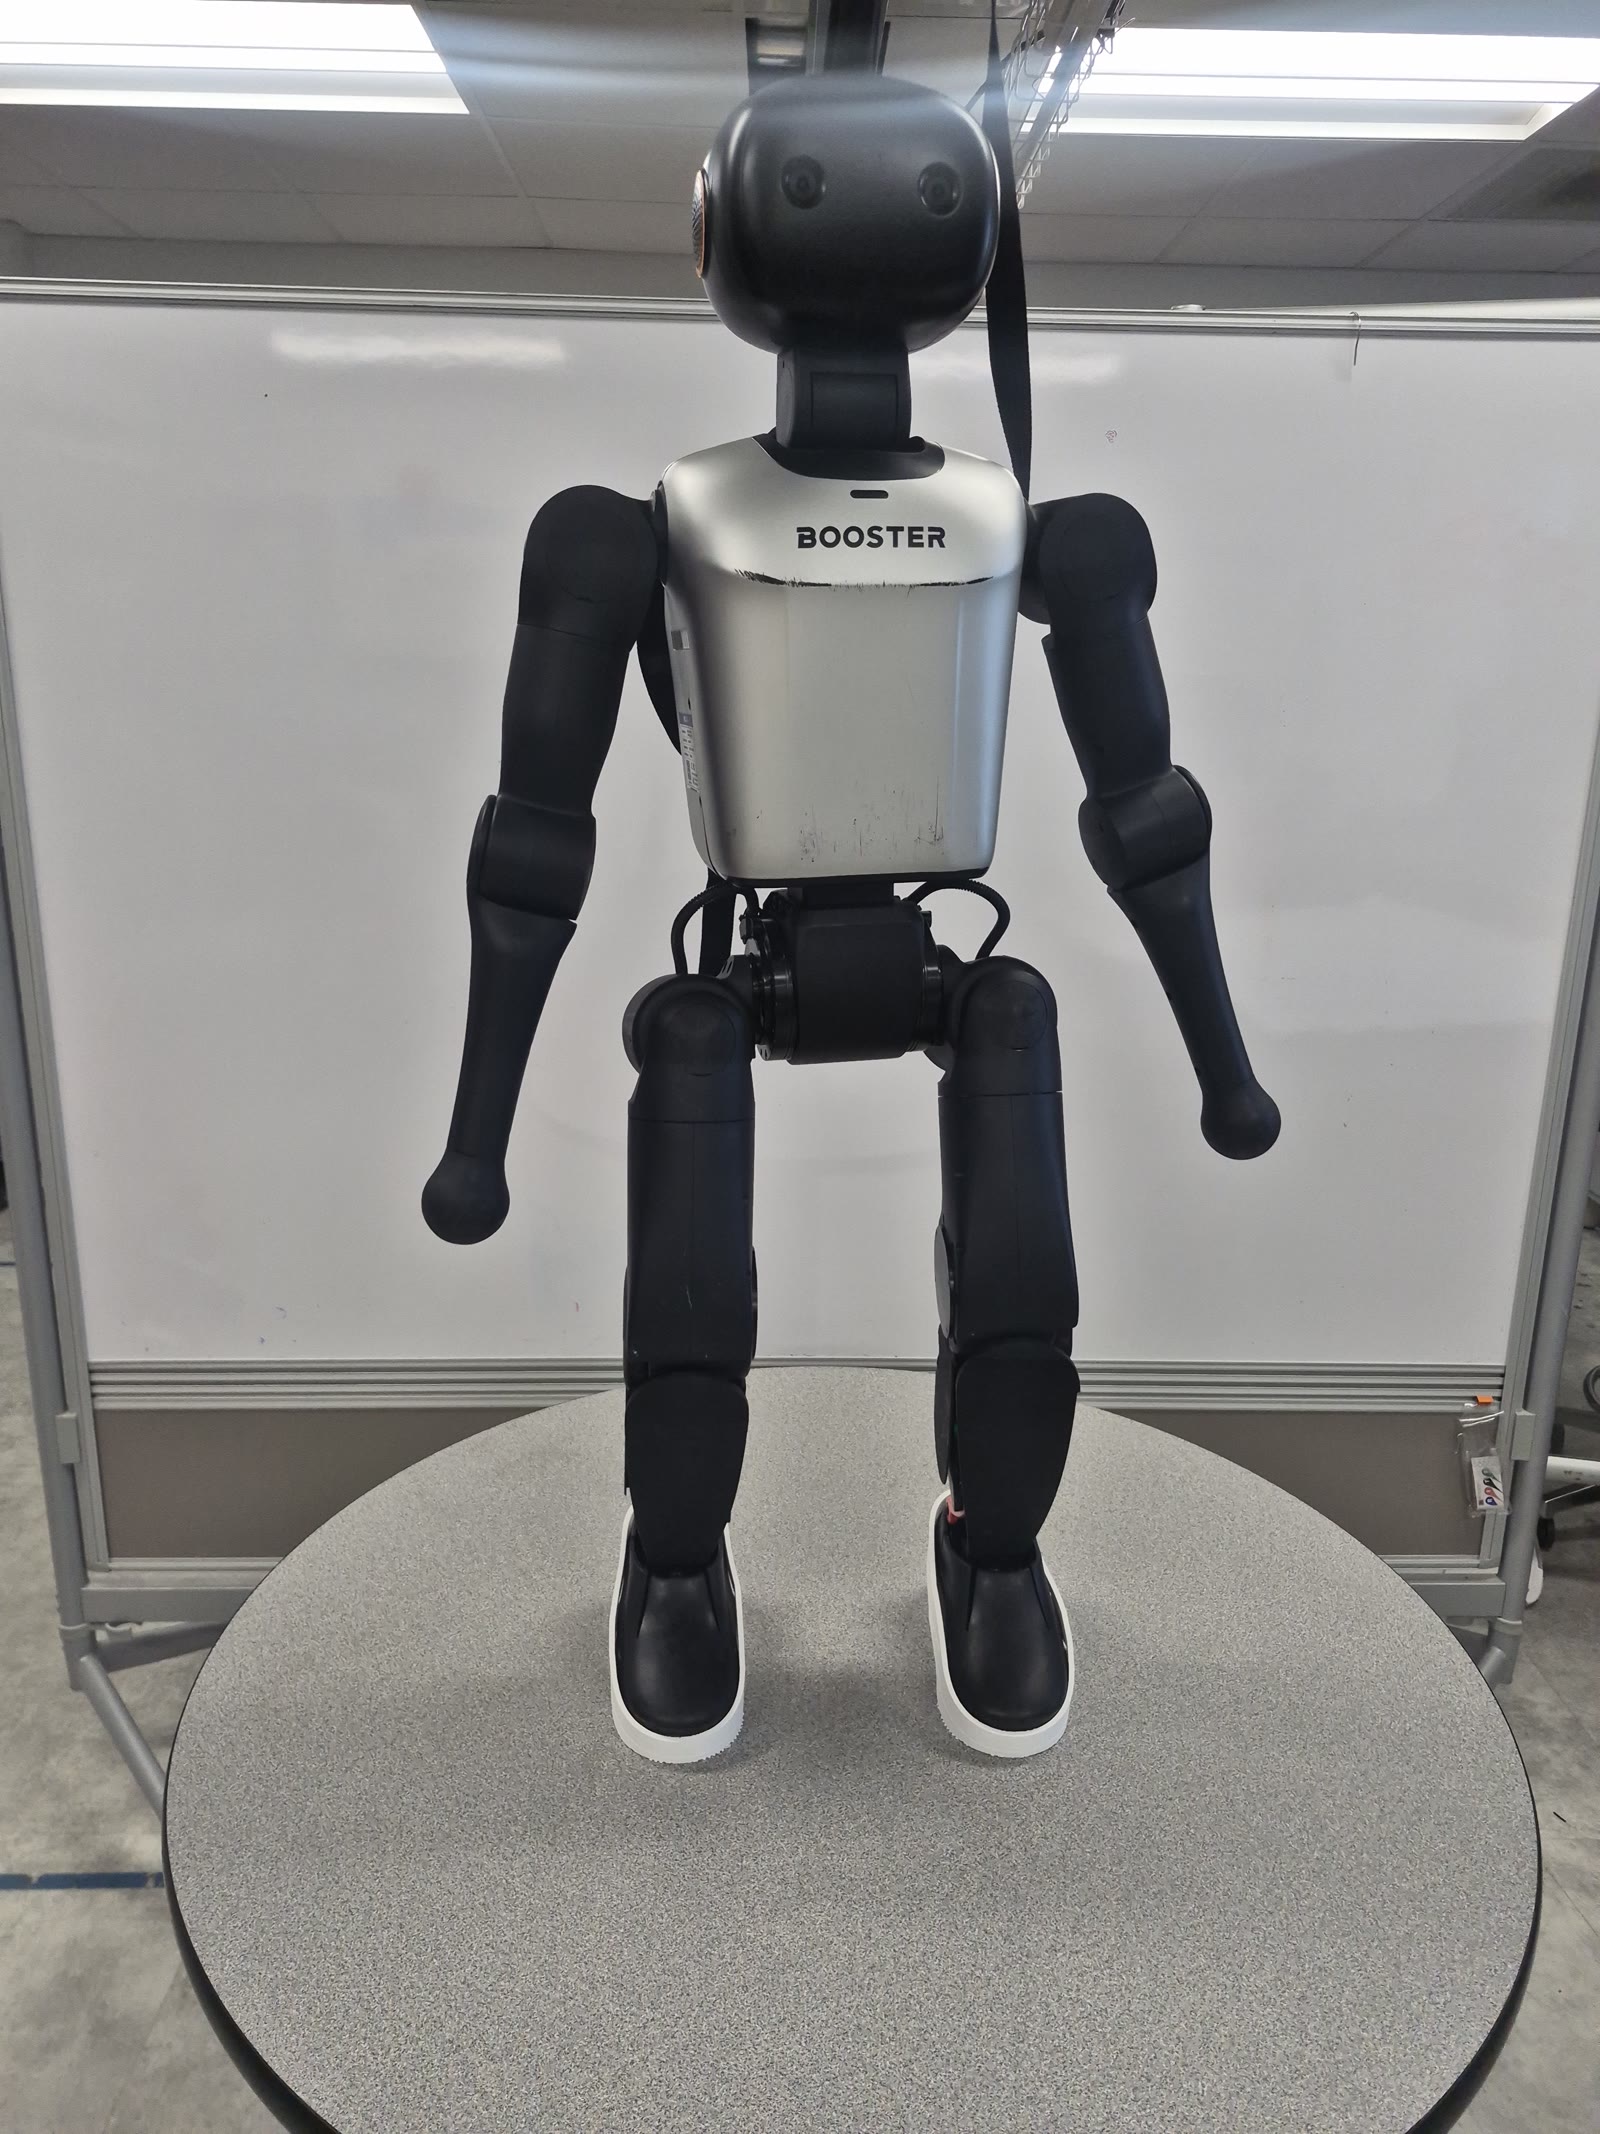
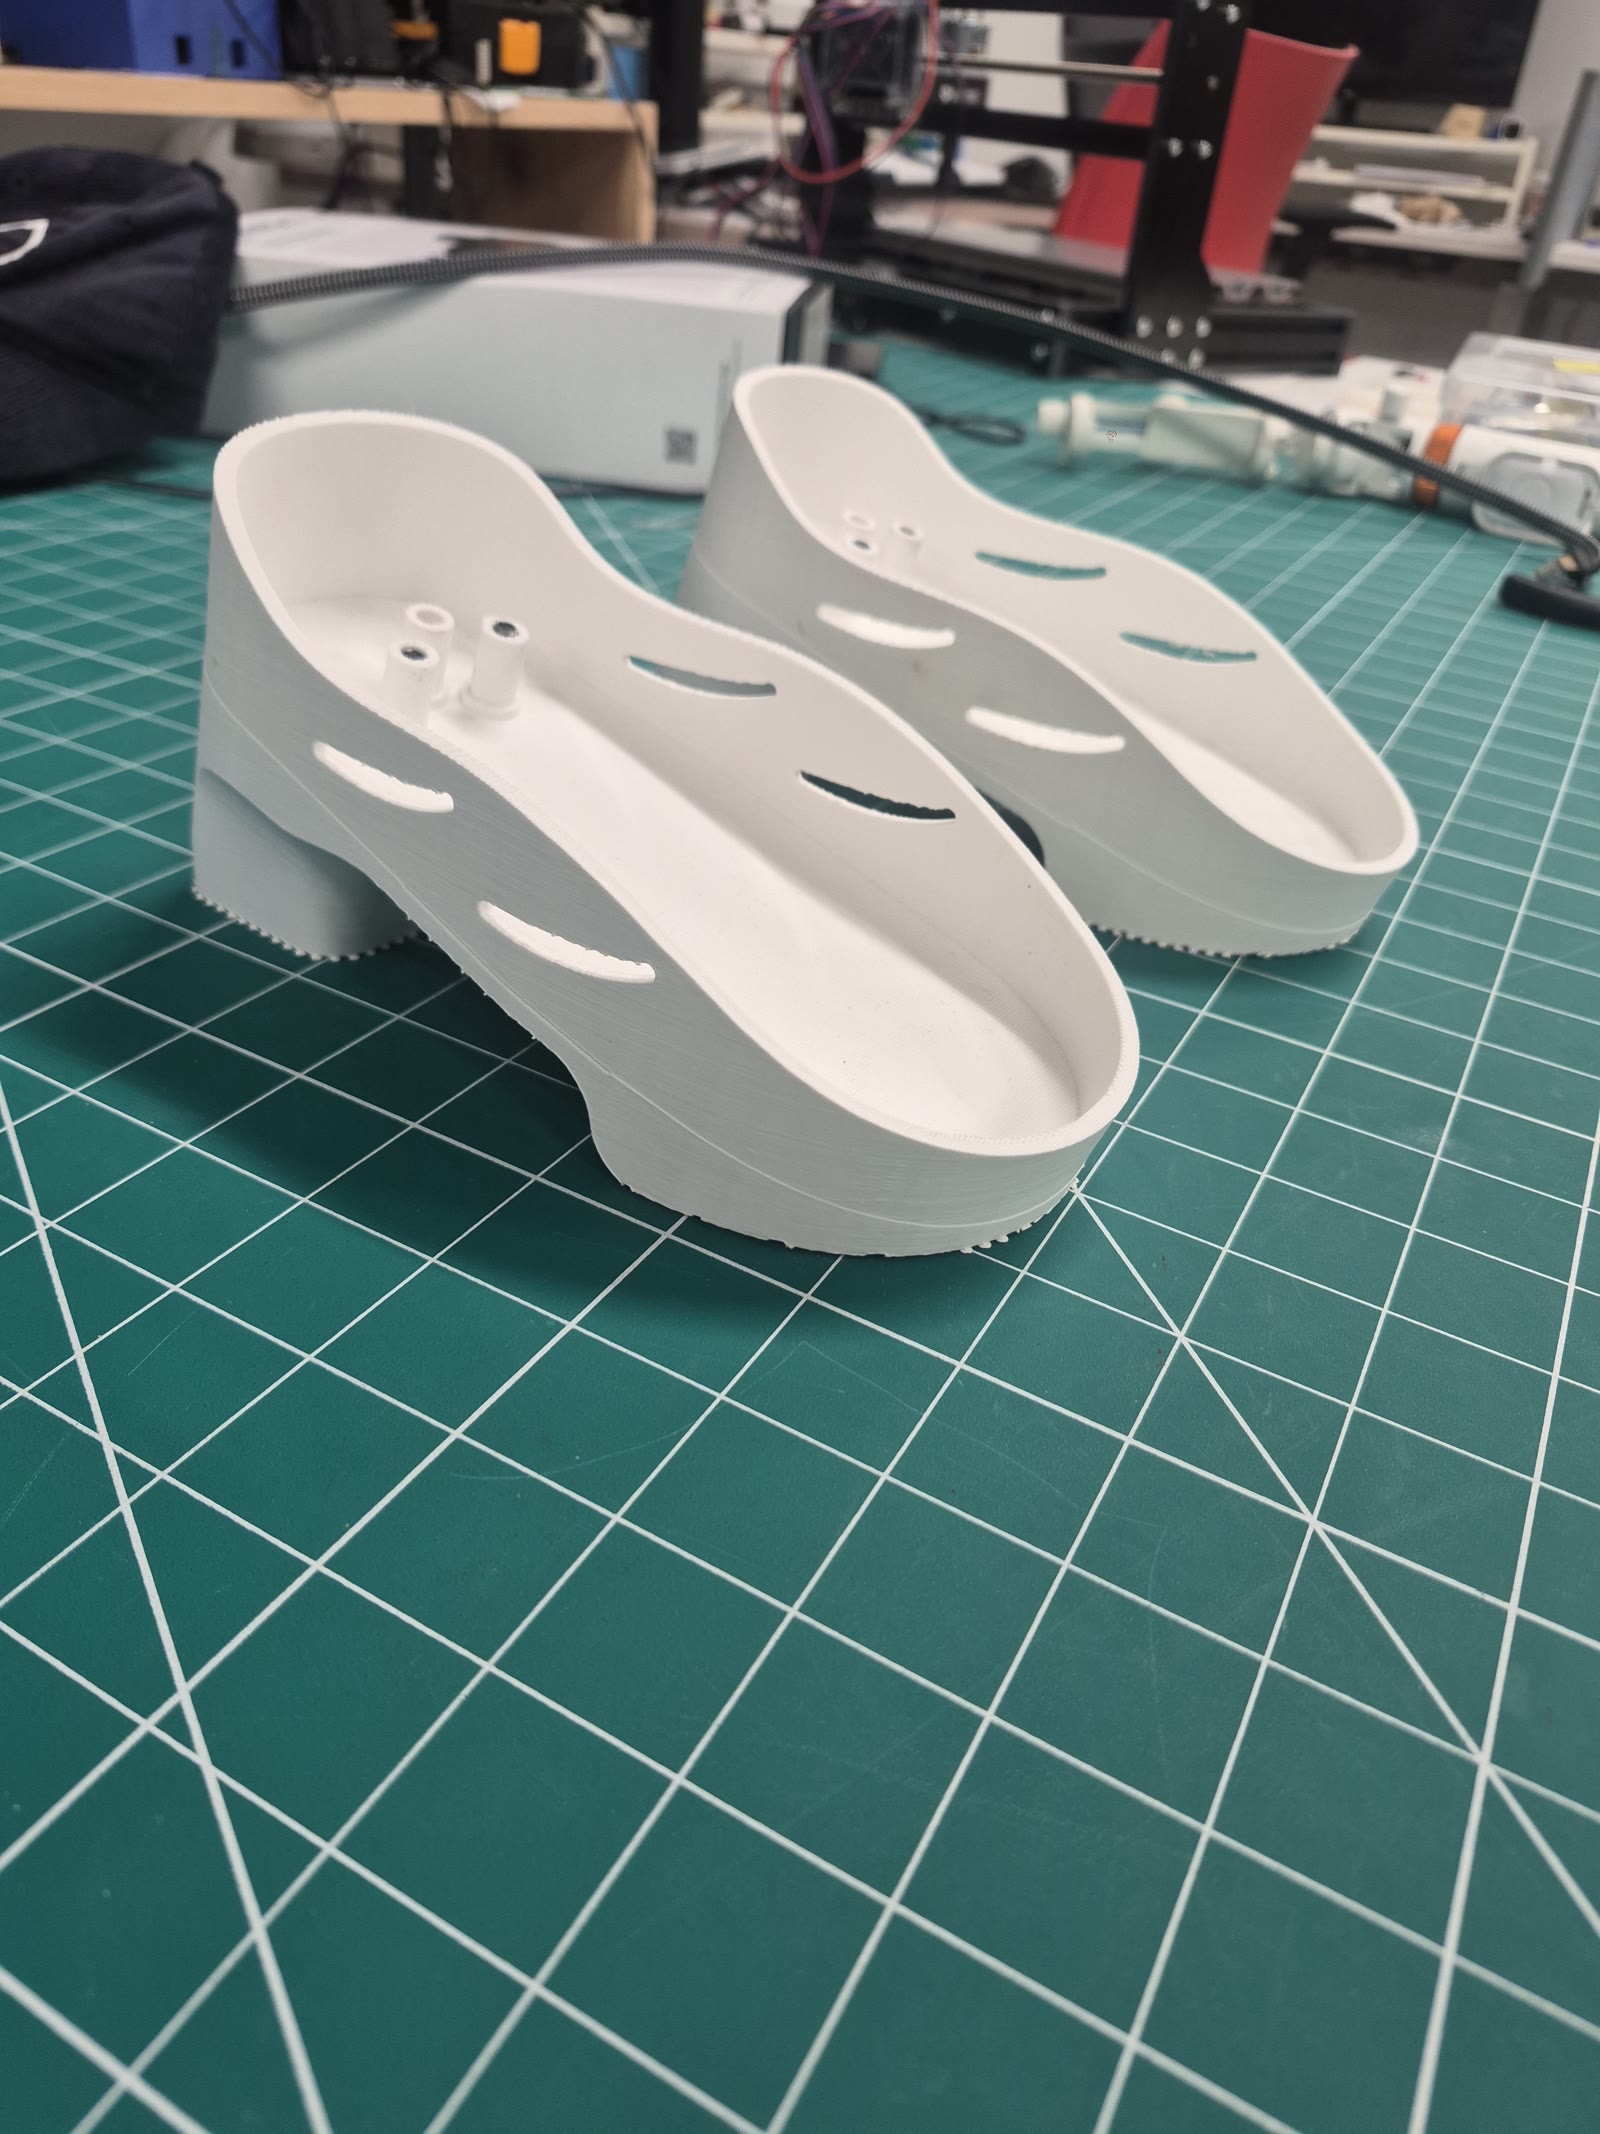
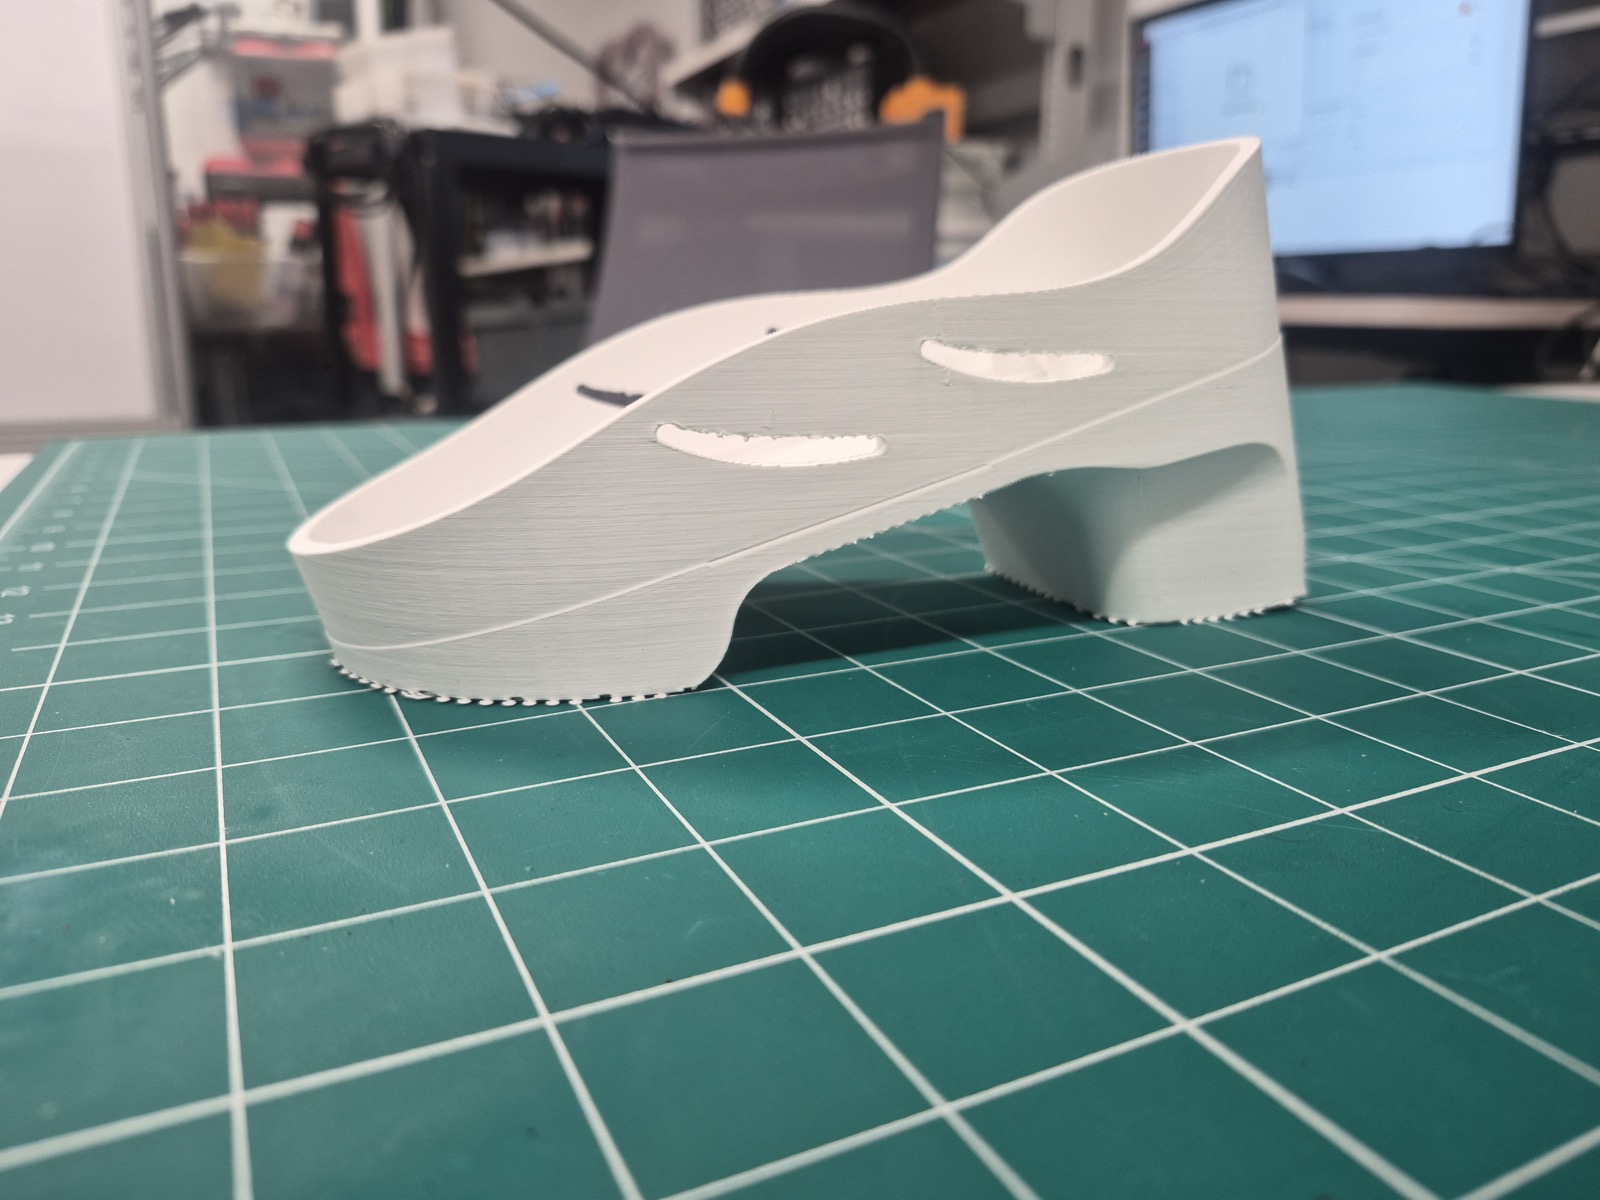
I made heel shoes for the K1 for runway walks. The 50 mm pair is printed and on the robot. I also have 20, 30 and 40 mm versions of the same shoe, not printed yet.
| Heel | 50 mm |
| Sole pitch | ~15.6° toe down |
| Sole below the bare foot | 58.5 mm |
| Weight | ~350 g per shoe |
| Mounting | three screws through the posts in the footbed |
The STEP and STL files for both shoes are on GitHub, with sim meshes and MuJoCo / URDF models of the K1 wearing them.
Walking in them: K1 Heel Walking.