kyry.me

Kyrylo Kolesnichenko
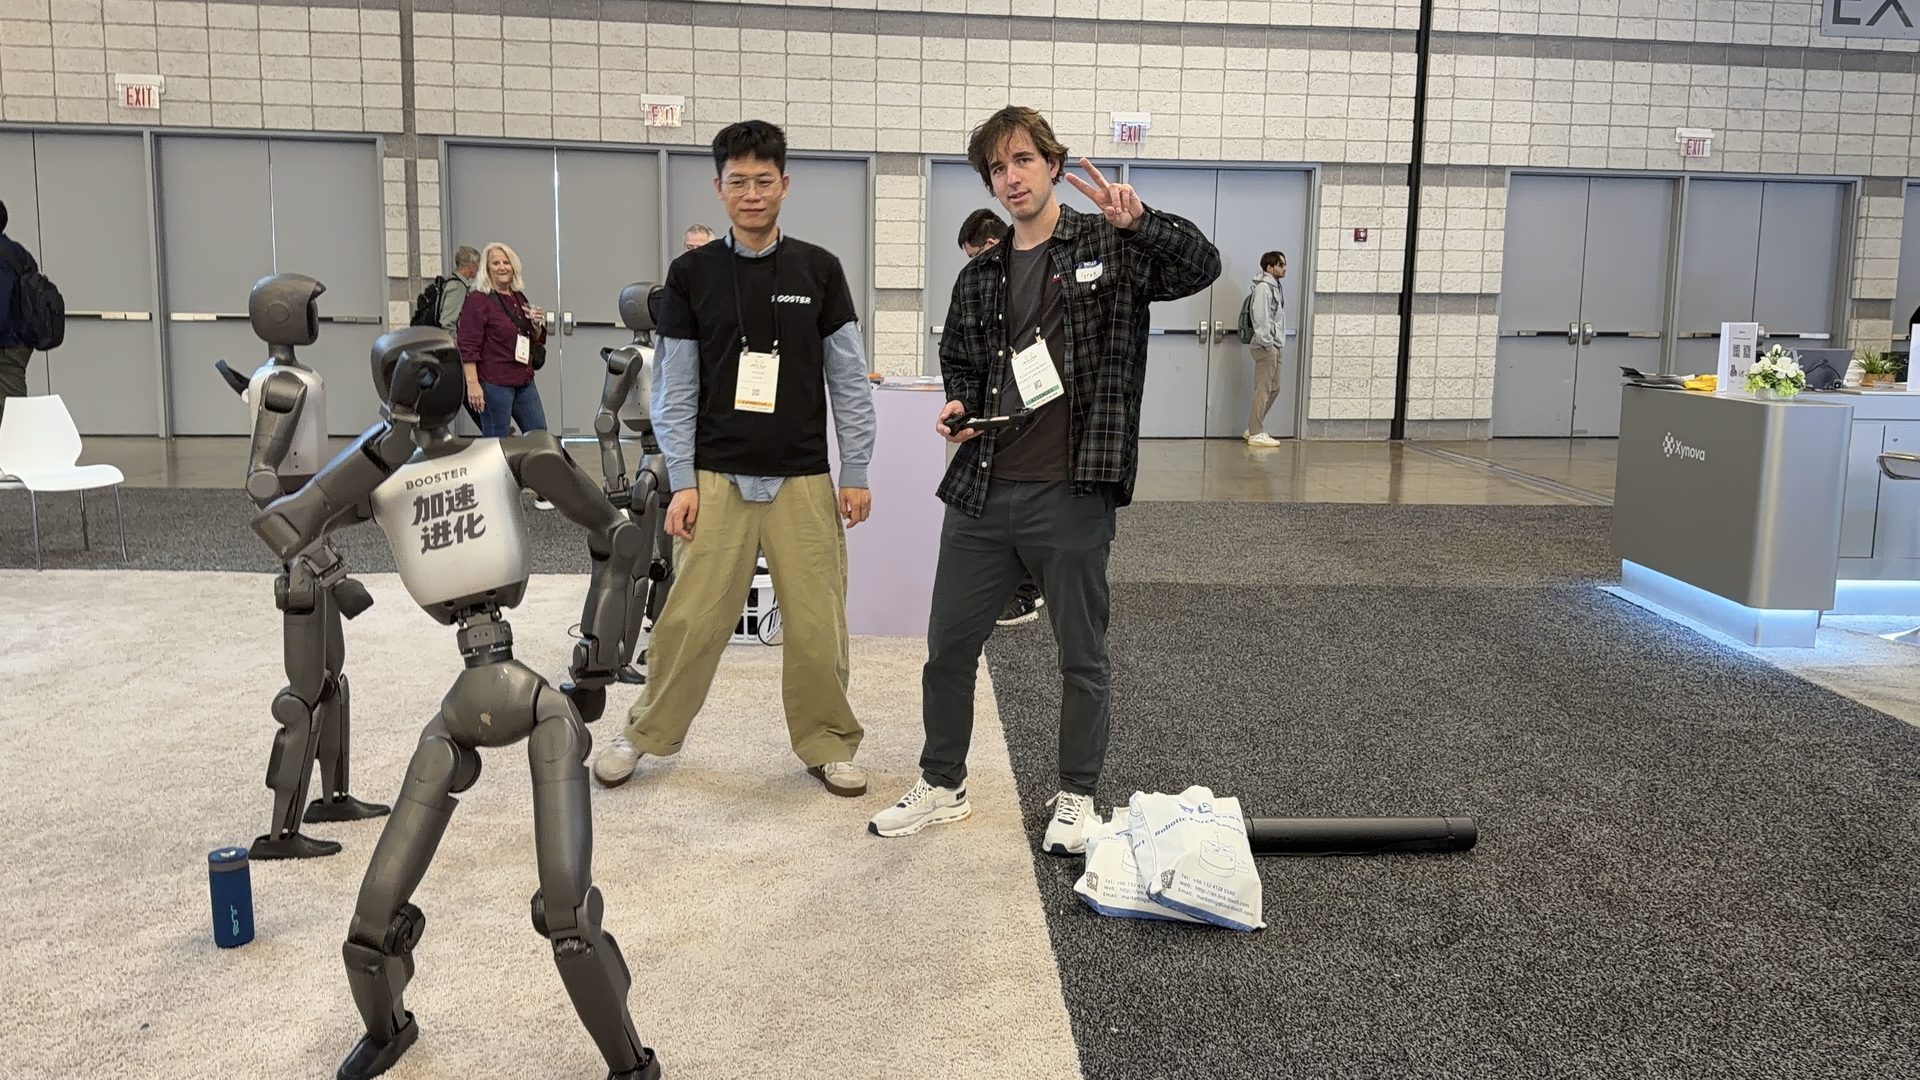
Kyrylo Kolesnichenko holding a robot controller next to Booster Robotics humanoids and a Booster team member, in a conference exhibit hall
CH1IROS 2026, Pittsburgh: at the Booster Robotics booth.

I’m a final-year undergraduate at Vilnius University and a researcher at Kent State University’s Advanced Telerobotics Research Lab, advised by Jong-Hoon Kim.

My main interests are reinforcement learning and humanoid robotics. I develop and test control policies in simulation and on hardware, working on expressive motion, locomotion for teleoperation, and walking with different foot geometries. I also work on bipedal running and LLM-based human–robot interaction.

Specification

robots
Booster K1 ×8Pepper ×1Microduck ×1Unitree G1 ×1
robotics / rl
Isaac Lab/Sim · mjlab · MuJoCo · ROS 2 · PPO/RSL-RL · AMP · BeyondMimic · NVIDIA SONIC · GVHMR · GMR · sim-to-real
ml / ai
PyTorch · Hugging Face · vLLM · ONNX Runtime · OpenCV · scikit-learn · TensorFlow · LLMs · VLMs · RAG · FAISS
languages
Python · SQL · JavaScript/TypeScript · Bash · R · LaTeX
systems
Linux · Git · Docker · conda · CMake · CUDA · H100 GPU servers · FastAPI · PostgreSQL · React · Node.js · CAD · 3D printing
record
12 projects · 3 papers · 41 videos and photos

Projects

  • P-11SONIC-K12026-10

    NVIDIA's SONIC whole-body motion tracker, ported to the Booster K1 and trained from scratch with under 1% of the original compute. The first open-weights motion tracker for the K1.

    Booster K1 · released, simulation

    3 media

  • P-01Expressive Motion2026 – 2026-09

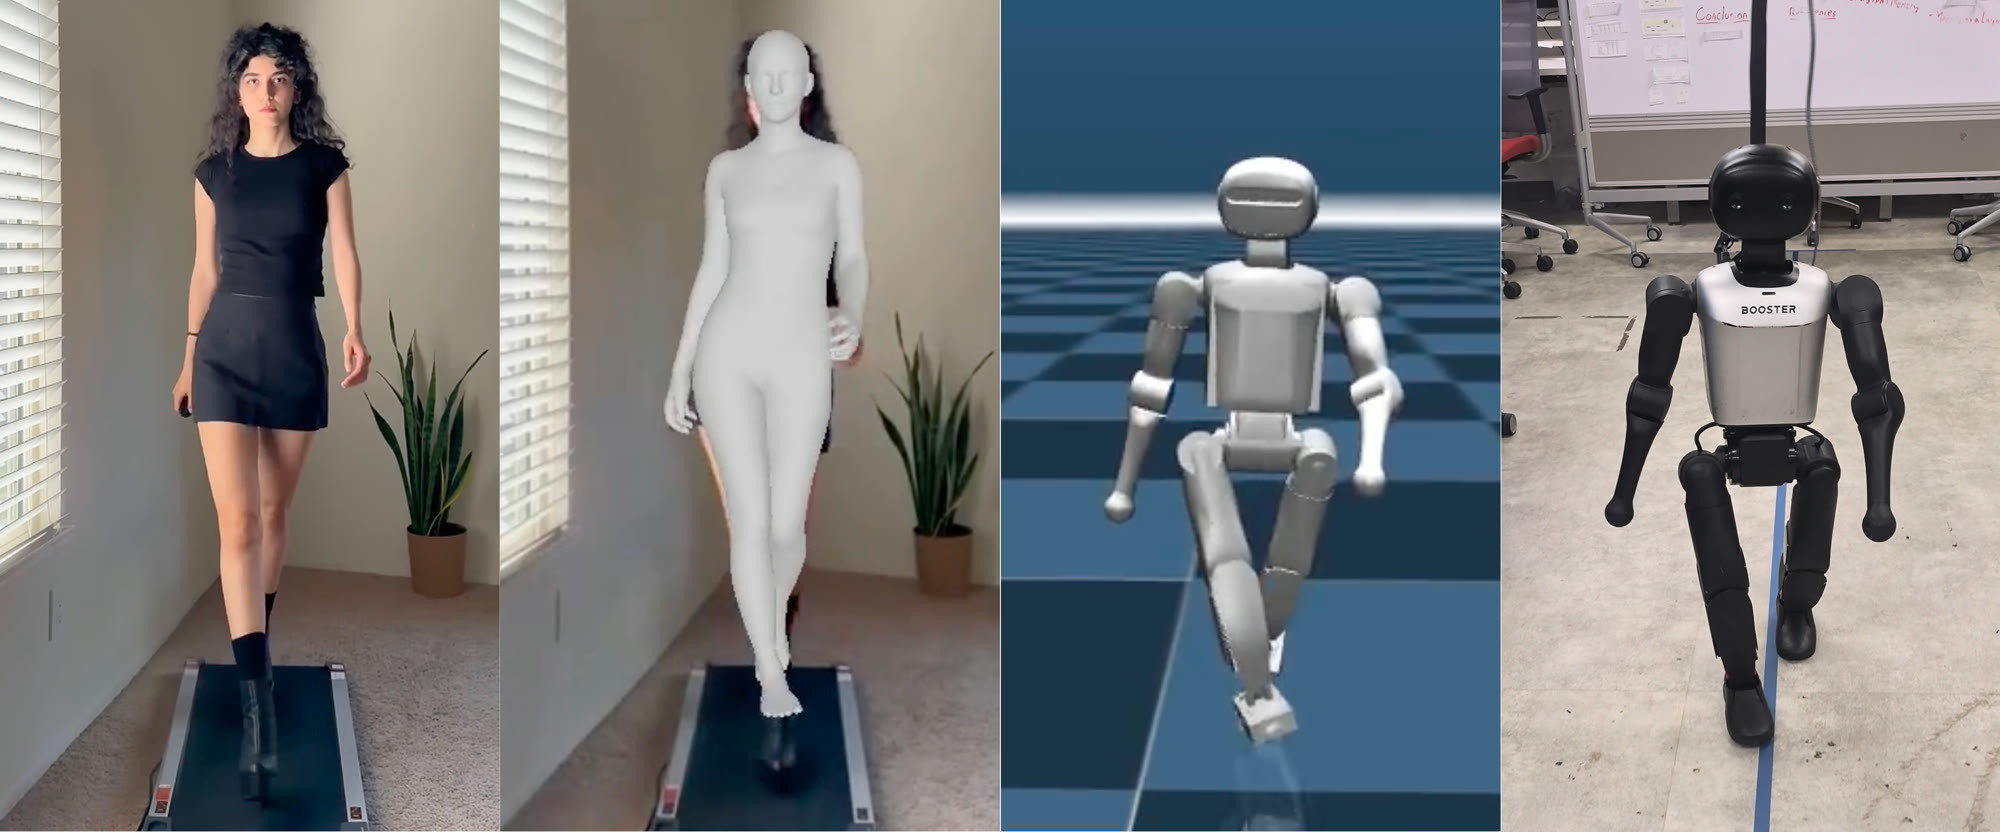
    From a monocular runway video to a catwalk gait on the Booster K1.

    Booster K1 · IROS 2026 Late Breaking Results (LBR) · published code, poster presented

    1 paper · 5 media

  • P-03RFCP, Robot Fashion Catwalk Policy2026-08 – 2026-09

    Our Ghost Trial 04 entry. A G1 walks the runway, turns, poses and walks back, by fine-tuning SONIC.

    Unitree G1 · Ultimate Bots Ghost Trial 04, Performance Arts · submitted, simulation

    3 media

  • P-04K1 Shoes2026-09 – present

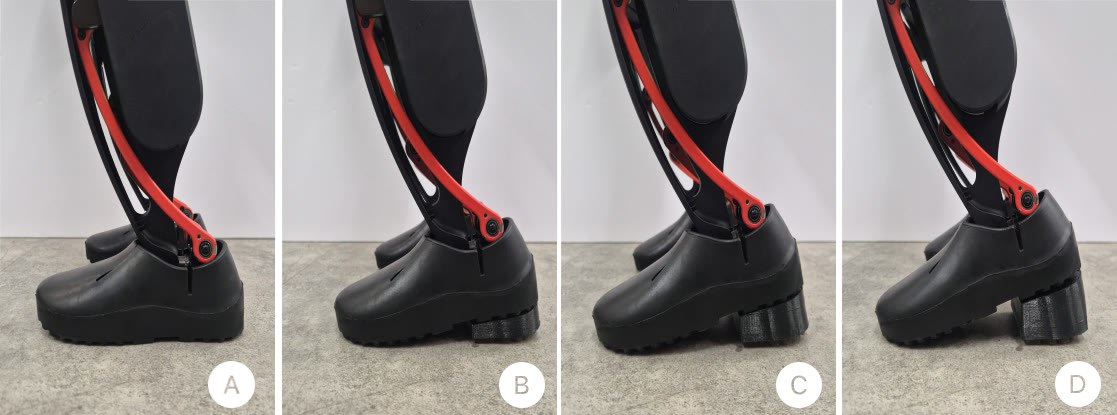
    3D-printed shoes for the Booster K1. Heels for runway walks, plus Dutch clogs and a light vine pair for the Humanoid Robot Fashion Challenge. Open source, with MuJoCo and URDF models of the K1 wearing them.

    Booster K1 · open source, 50 mm heels fitted

    10 media

  • P-06K1 Loco-Teleop2026-10 – present

    A walking policy for the Booster K1 that drives only the legs, so the arms and head stay free for teleoperation.
    Booster K1 · in progress, simulation

    1 media

all 12 projects →

Selected publications

  • [1]
    Learning Expressive Humanoid Locomotion from Monocular Runway Videos for Robot Fashion ShowsKyrylo Kolesnichenko, Irvin Steve Cardenas, Jong-Hoon Kim.IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), Late Breaking Results (LBR), 2026 · presented, posterarXivpdfcodevideoproject
    BibTeX
    @inproceedings{kolesnichenko2026learning,
      title         = {{Learning Expressive Humanoid Locomotion from Monocular Runway Videos for Robot Fashion Shows}},
      author        = {Kolesnichenko, Kyrylo and Cardenas, Irvin Steve and Kim, Jong-Hoon},
      booktitle     = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), Late Breaking Results (LBR)},
      year          = {2026},
      eprint        = {2609.27003},
      archivePrefix = {arXiv}
    }
  • [2]
    Can Structured Prompting Overcome Knowledge Bias in Vision-Language Models?Kyrylo Kolesnichenko, Martas Ambraziunas.Proceedings of the 31st International Conference on Information Society and University Studies (IVUS 2026), CEUR Workshop Proceedings, 2026 · presented, to appearcodeproject
    BibTeX
    @inproceedings{kolesnichenko2026structured,
      title     = {{Can Structured Prompting Overcome Knowledge Bias in Vision-Language Models?}},
      author    = {Kolesnichenko, Kyrylo and Ambraziunas, Martas},
      booktitle = {Proceedings of the 31st International Conference on Information Society and University Studies (IVUS 2026)},
      address   = {Kaunas, Lithuania},
      series    = {CEUR Workshop Proceedings},
      year      = {2026},
      note      = {To appear}
    }
  • [3]
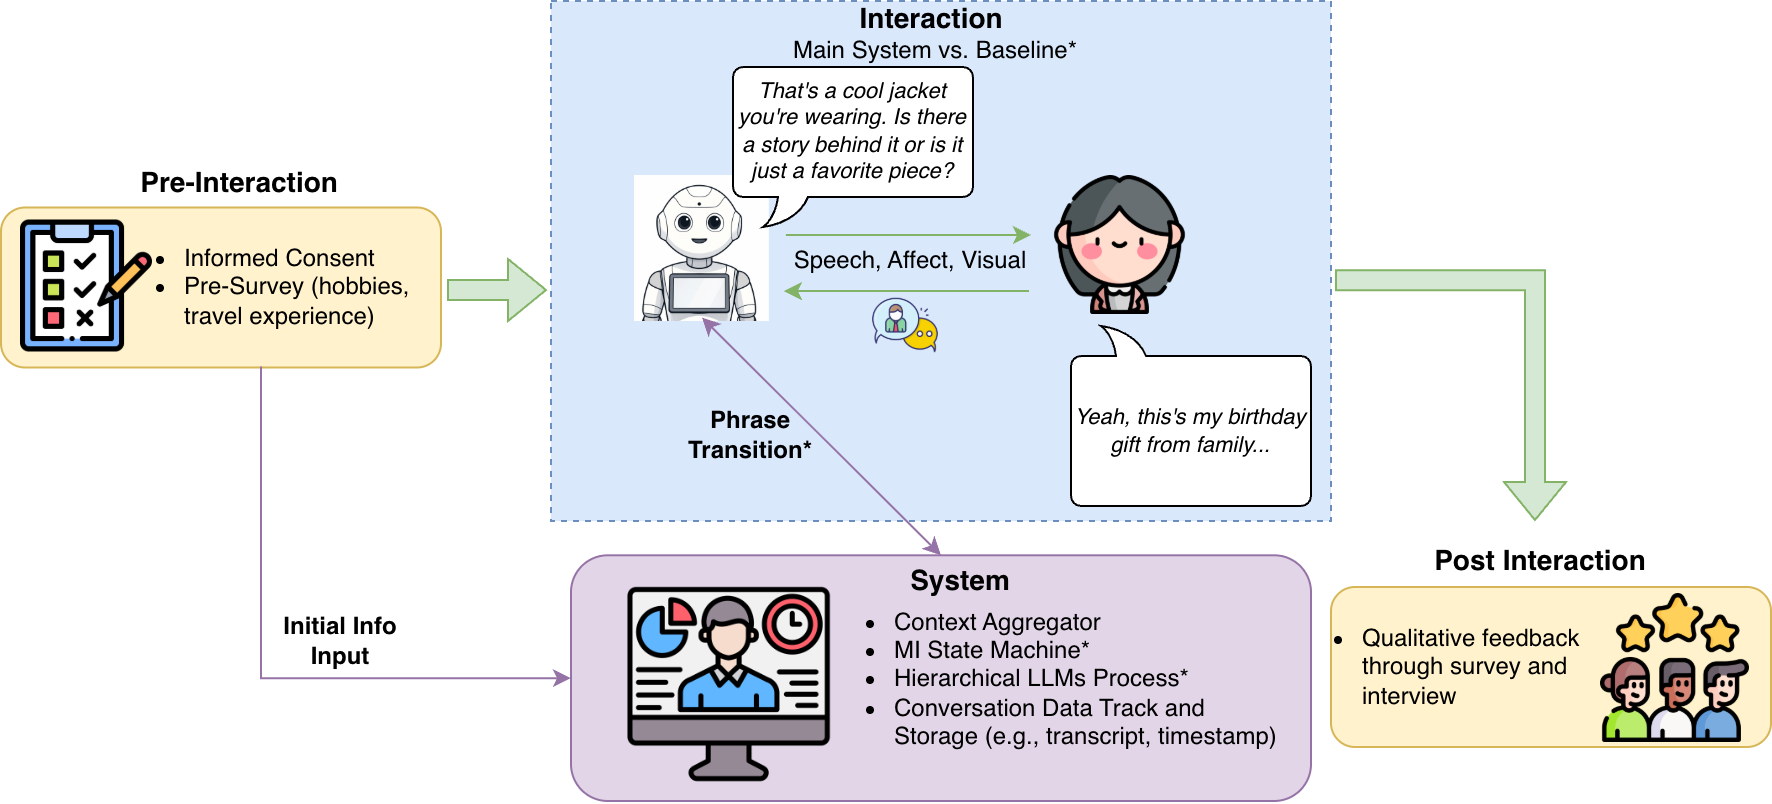
    Can Motivational Interviewing Guided Dialogue Improve Empathy in Human–Robot Interaction? A Controlled Study with Baseline ComparisonRaiyan Ashraf, Yanni Liu, Kyrylo Kolesnichenko, Sruthi Ganji, Jong-Hoon Kim, Ju Yup Lee.International Conference on Intelligent Human–Computer Interaction (IHCI 2026), 2026 · acceptedproject
    BibTeX
    @inproceedings{ashraf2026motivational,
      title     = {{Can Motivational Interviewing Guided Dialogue Improve Empathy in Human–Robot Interaction? A Controlled Study with Baseline Comparison}},
      author    = {Ashraf, Raiyan and Liu, Yanni and Kolesnichenko, Kyrylo and Ganji, Sruthi and Kim, Jong-Hoon and Lee, Ju Yup},
      booktitle = {International Conference on Intelligent Human–Computer Interaction (IHCI 2026)},
      year      = {2026}
    }
  • [4]The Booster K1 foot in four heel heights, A to D
    Walking in Heels: Heel-Aware Humanoid Gait Under Changing Contact GeometryIEEE International Conference on Robotics and Automation (ICRA 2027) · under review

all publications →

Recent posts

all posts →