Summary
Robots keep showing up at fashion shows, but none of them walks like a model. Stock SONIC walks a runway like a hallway. For Ghost Trial 04 we fine-tuned NVIDIA’s SONIC on the Unitree G1 to do a full catwalk: down the runway, turn, pose, walk back. It grew out of my catwalk AMP work on the K1.
How
- The catwalk clip, m7, was made on the SOMA human body, retargeted to the G1’s 29 joints and converted to SONIC’s motion format.
- Fine-tuned from the released SONIC checkpoint in Isaac Lab, three variants: m7 only, m7 ×14 plus 30 BONES-SEED walk and turn clips so it doesn’t forget normal walking, and m7 ×25 with the same clips.
- A checkpoint every 25 iterations, evaluated all the time. The winner is the ×14 mix at step 250: it passed all 30 control clips with no self-collisions and no extra jitter.
- Checked with SONIC’s eval plus our own: gait stats, jitter, self-collision, 32 held-out clips, runs with random mass, friction and pushes, and the ONNX policy in MuJoCo.
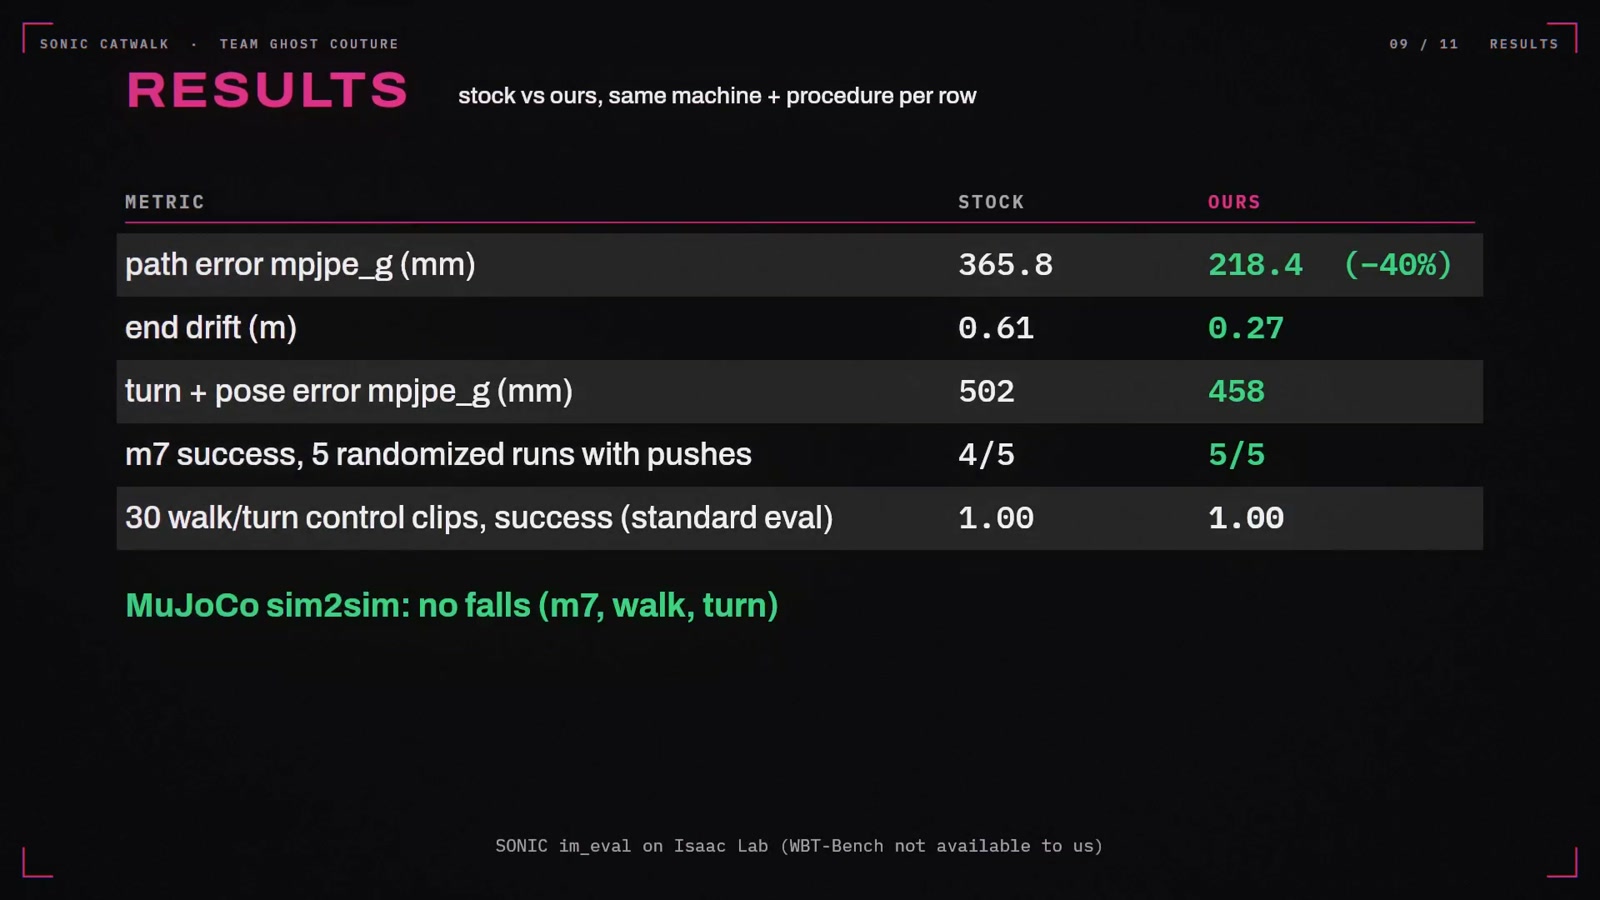
Results
| Stock SONIC | RFCP | |
|---|---|---|
| Catwalk path error | 366 mm | 218 mm |
| Turn and pose error | 502 mm | 458 mm |
| End drift from mark | 0.61 m | 0.27 m |
| Random mass, friction, pushes | 4/5 | 5/5, no falls |
| Walking and turning controls | 30/30 | 30/30 |
| ONNX in MuJoCo, drift | 0.64 m | 0.38 m, no falls |
What didn’t work: the steps stayed wide, 0.127 m against a 0.033 m target. So the result is a policy that hits its marks, not one with narrow model steps.
Release
Everything is open. Code on GitHub (MIT), the policy and ONNX files on Hugging Face under the NVIDIA Open Model License, and the catwalk dataset under CC BY 4.0. The BONES-SEED clips can’t be redistributed, so the dataset lists their names only.
Motion Data by Bones Studio. SONIC by NVIDIA.