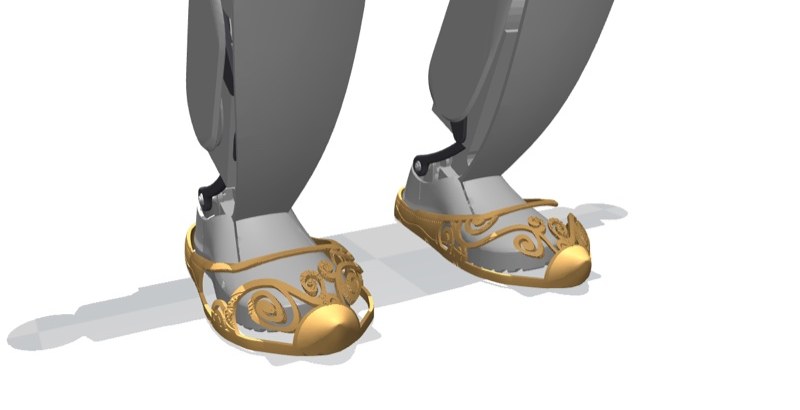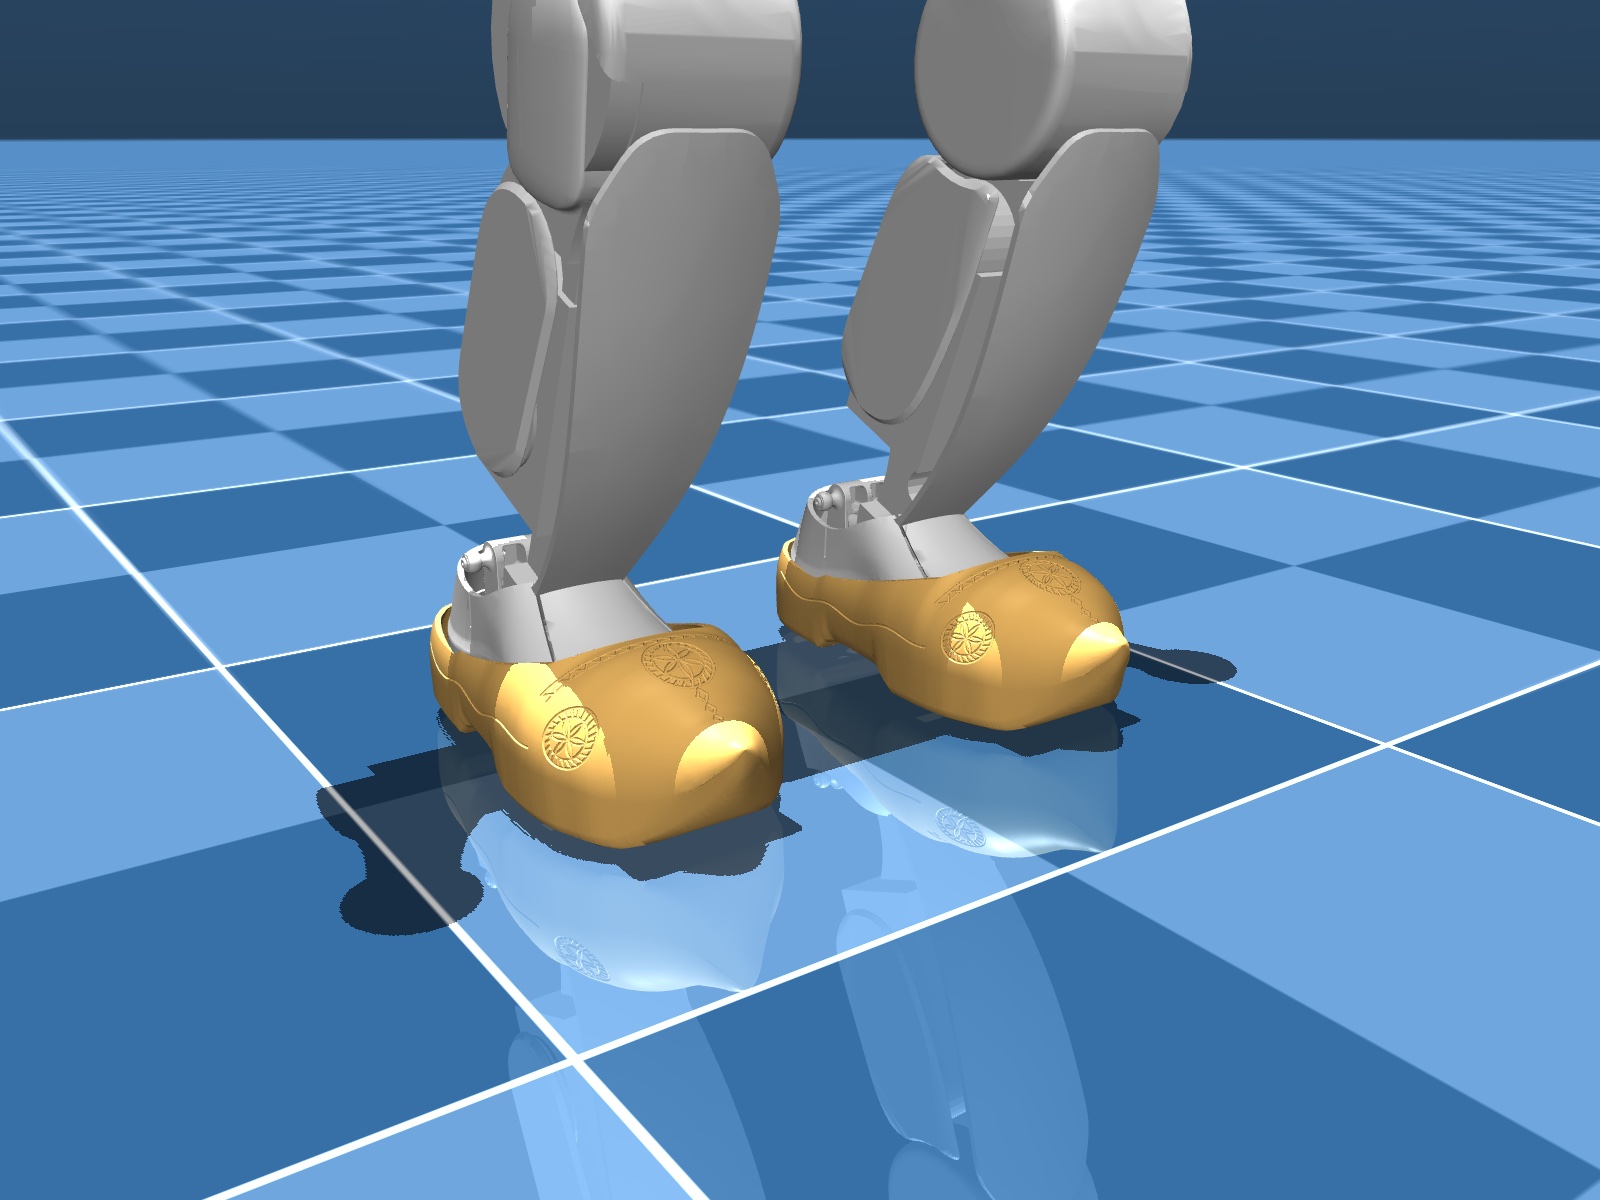
I designed 12 types of shoes for the Booster K1 for the Humanoid Robot Fashion Challenge, where our team won Best Humanoid Wearable/Accessory. The two we printed are now on GitHub:
- print-ready STLs for both feet, and the script that builds them;
- an ornate version with a heel rosette, tulips on the sides and a rope border;
- the light open-work pair with vines, plus two heavier vine versions;
- the K1 wearing the clogs in MuJoCo and as a URDF, with renders.
A dance policy trained barefoot also runs in the clogs in simulation without falling. Designs are CC BY 4.0, scripts MIT.