Summary
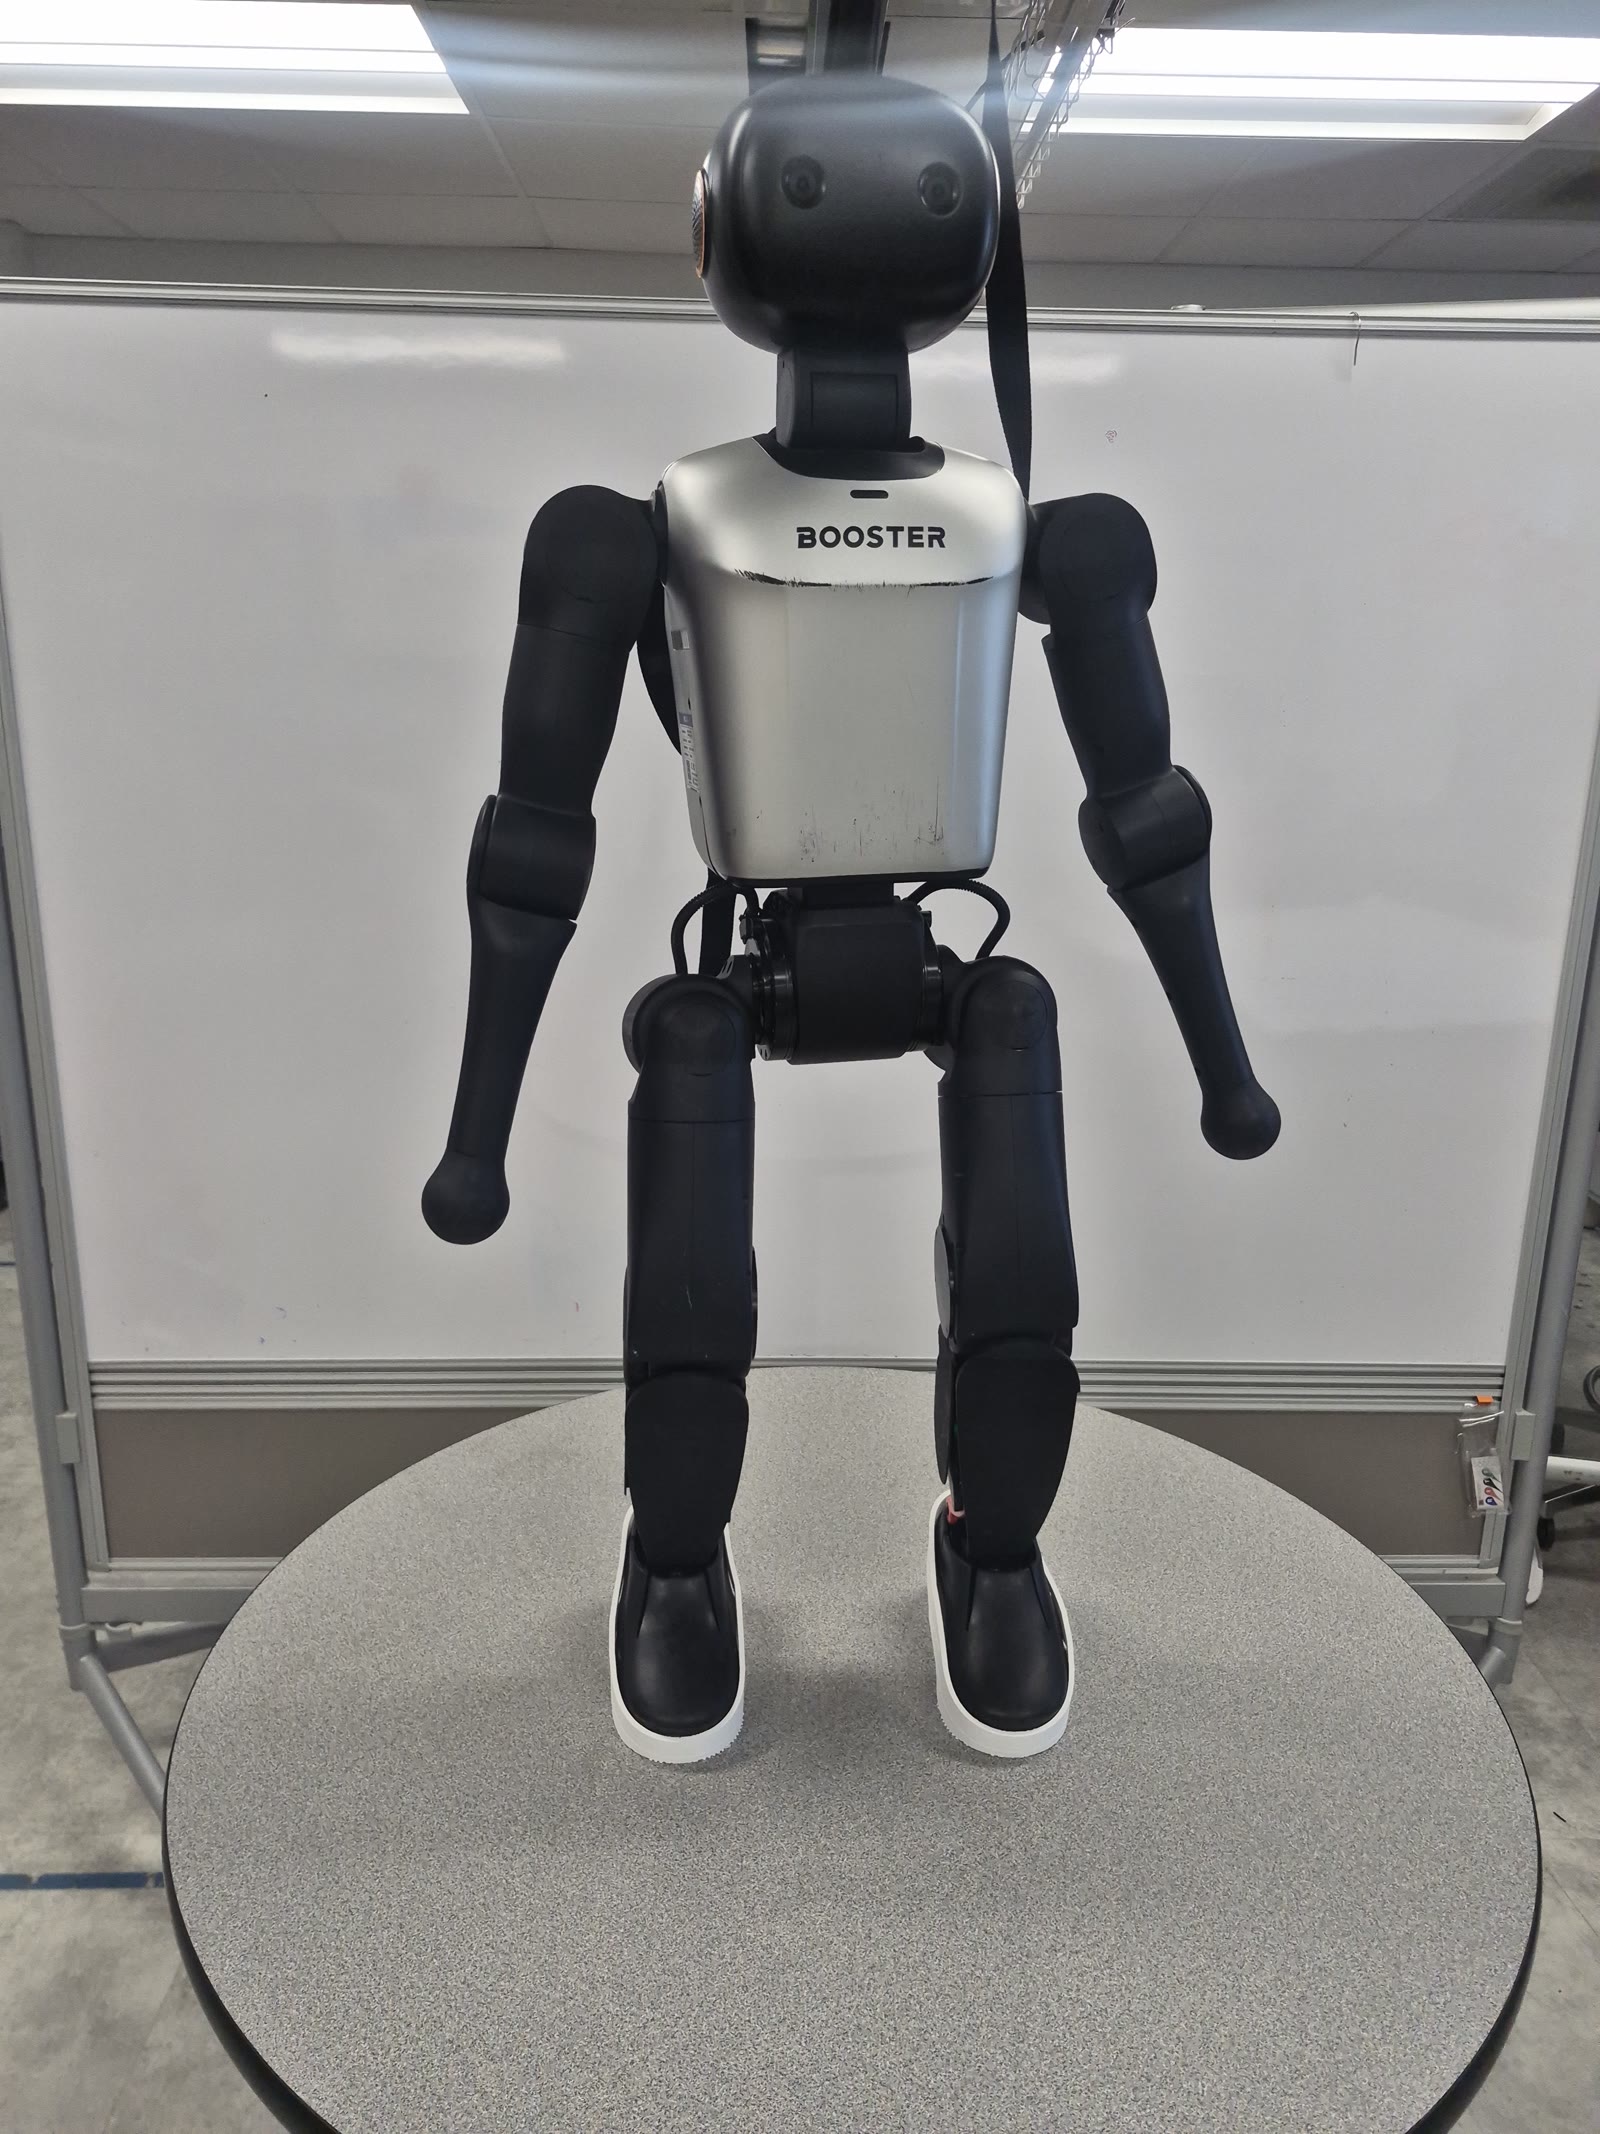
Shoes I designed and 3D printed for the Booster K1, in two open-source sets, each in its own repo:
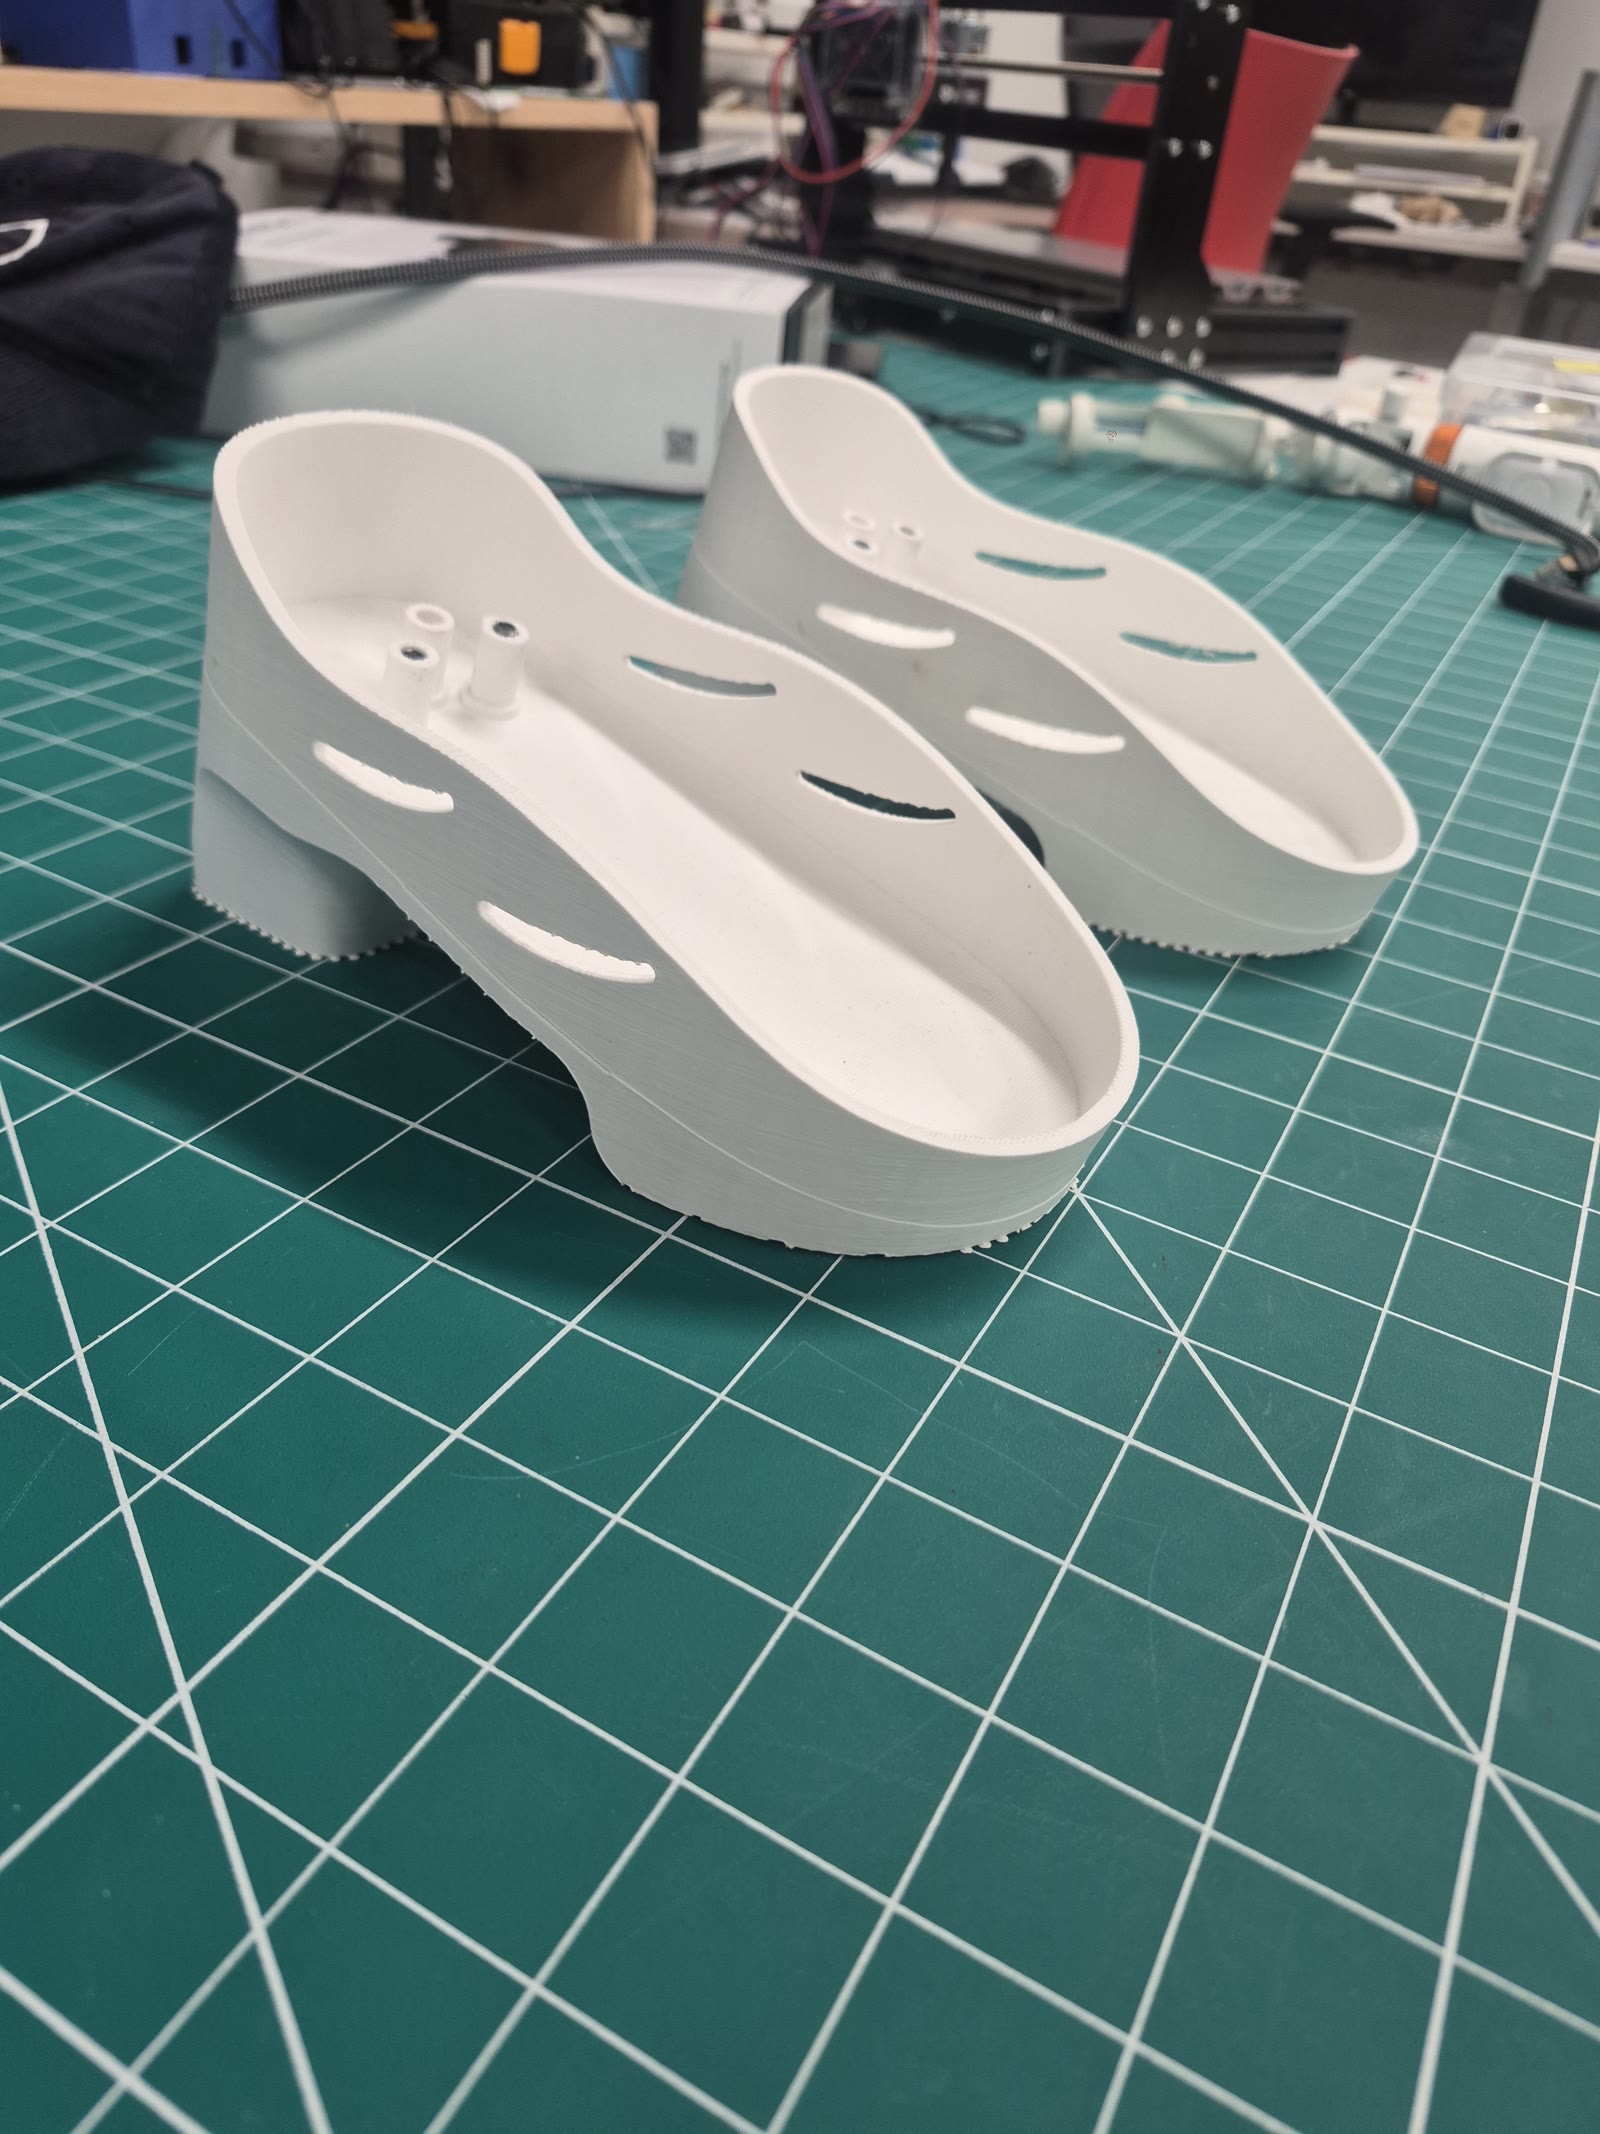
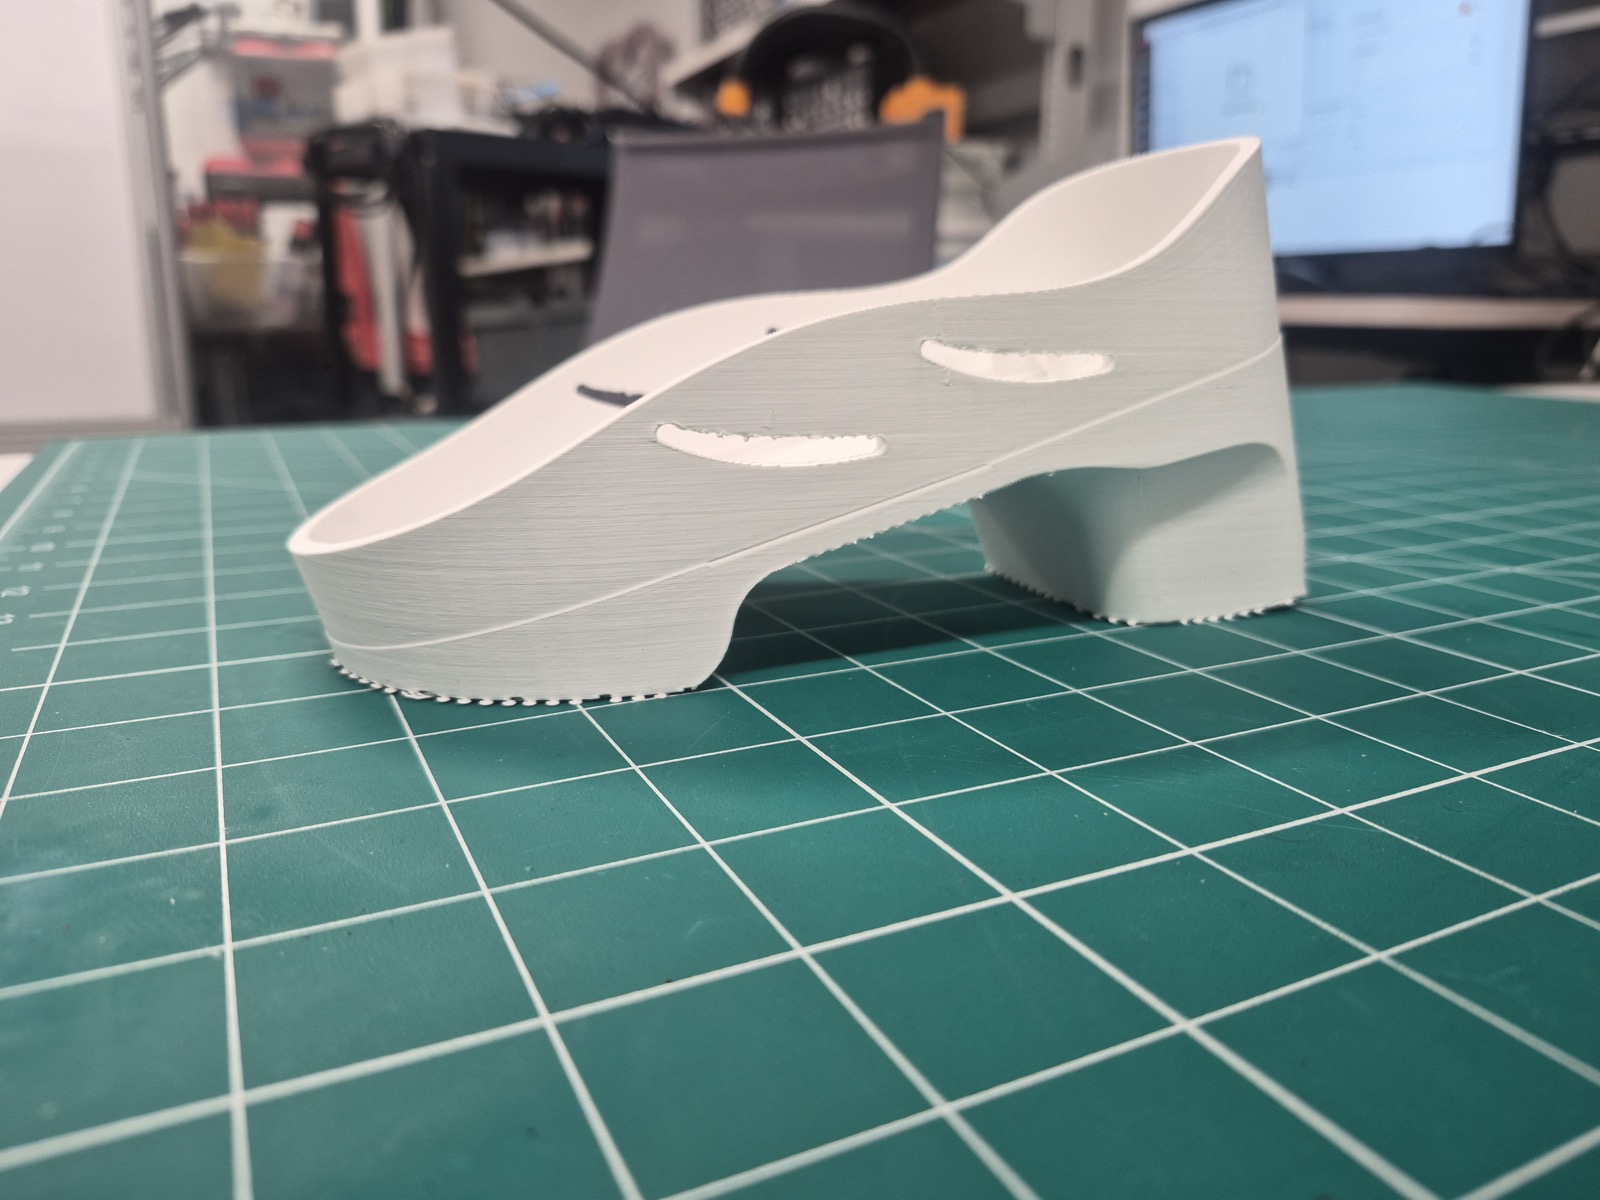
- Heels for runway walks. The 50 mm pair is printed and on the robot. Files.
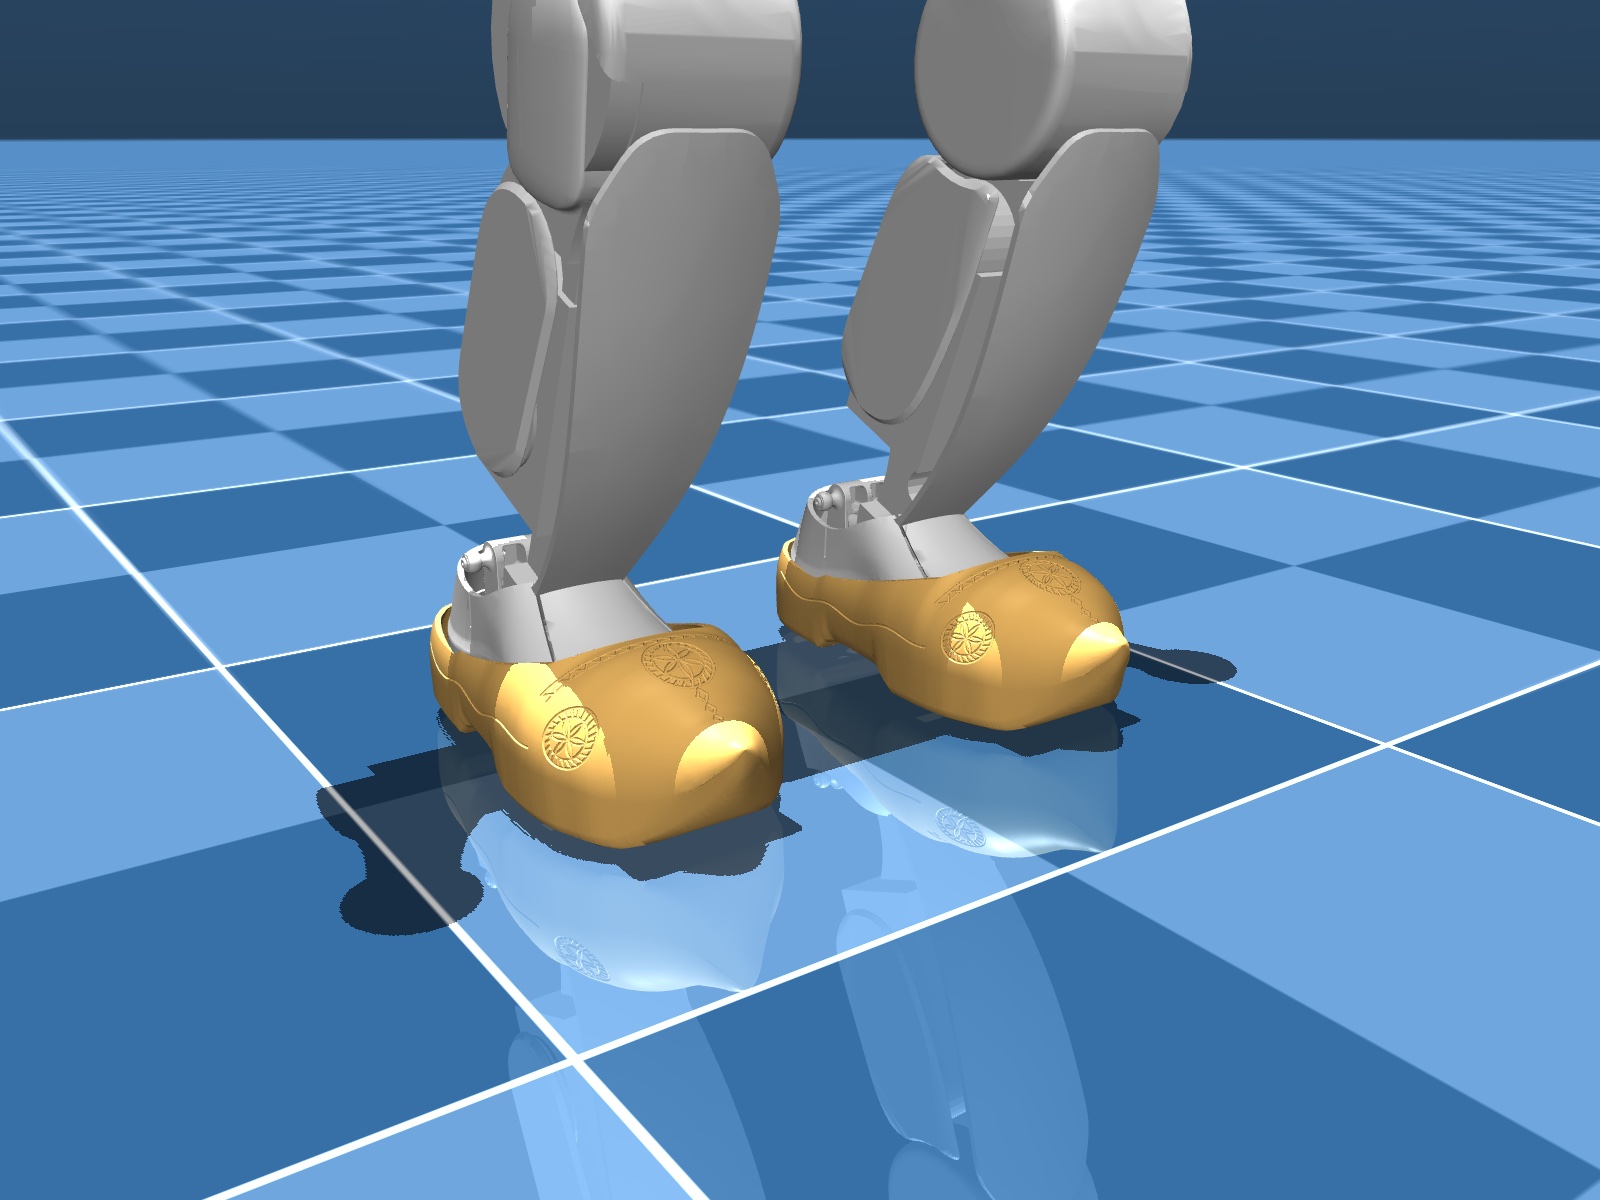
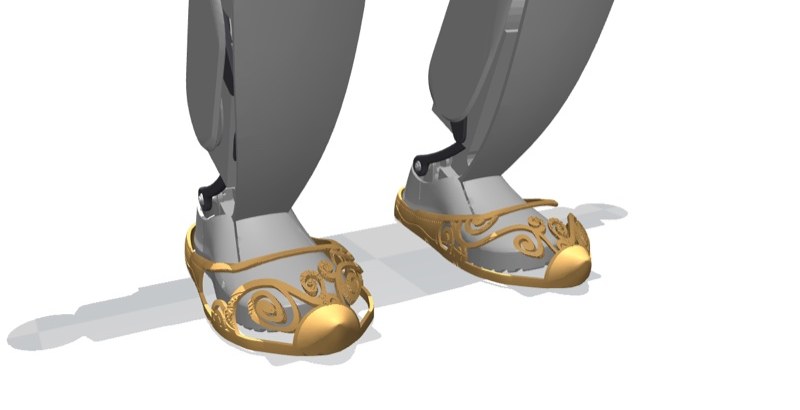
- Clogs and vines for the Humanoid Robot Fashion Challenge at Kent State, where our team won Best Humanoid Wearable/Accessory. Files.
Heels
I also have 20, 30 and 40 mm versions of the same shoe, not printed yet.
| Heel | 50 mm |
| Sole pitch | ~15.6° toe down |
| Sole below the bare foot | 58.5 mm |
| Weight | ~350 g per shoe |
| Mounting | three screws through the posts in the footbed |
The files have STEP and STL for both shoes, sim meshes, and MuJoCo / URDF models of the K1 wearing them. Walking in them: K1 Heel Walking.
Clogs and vines
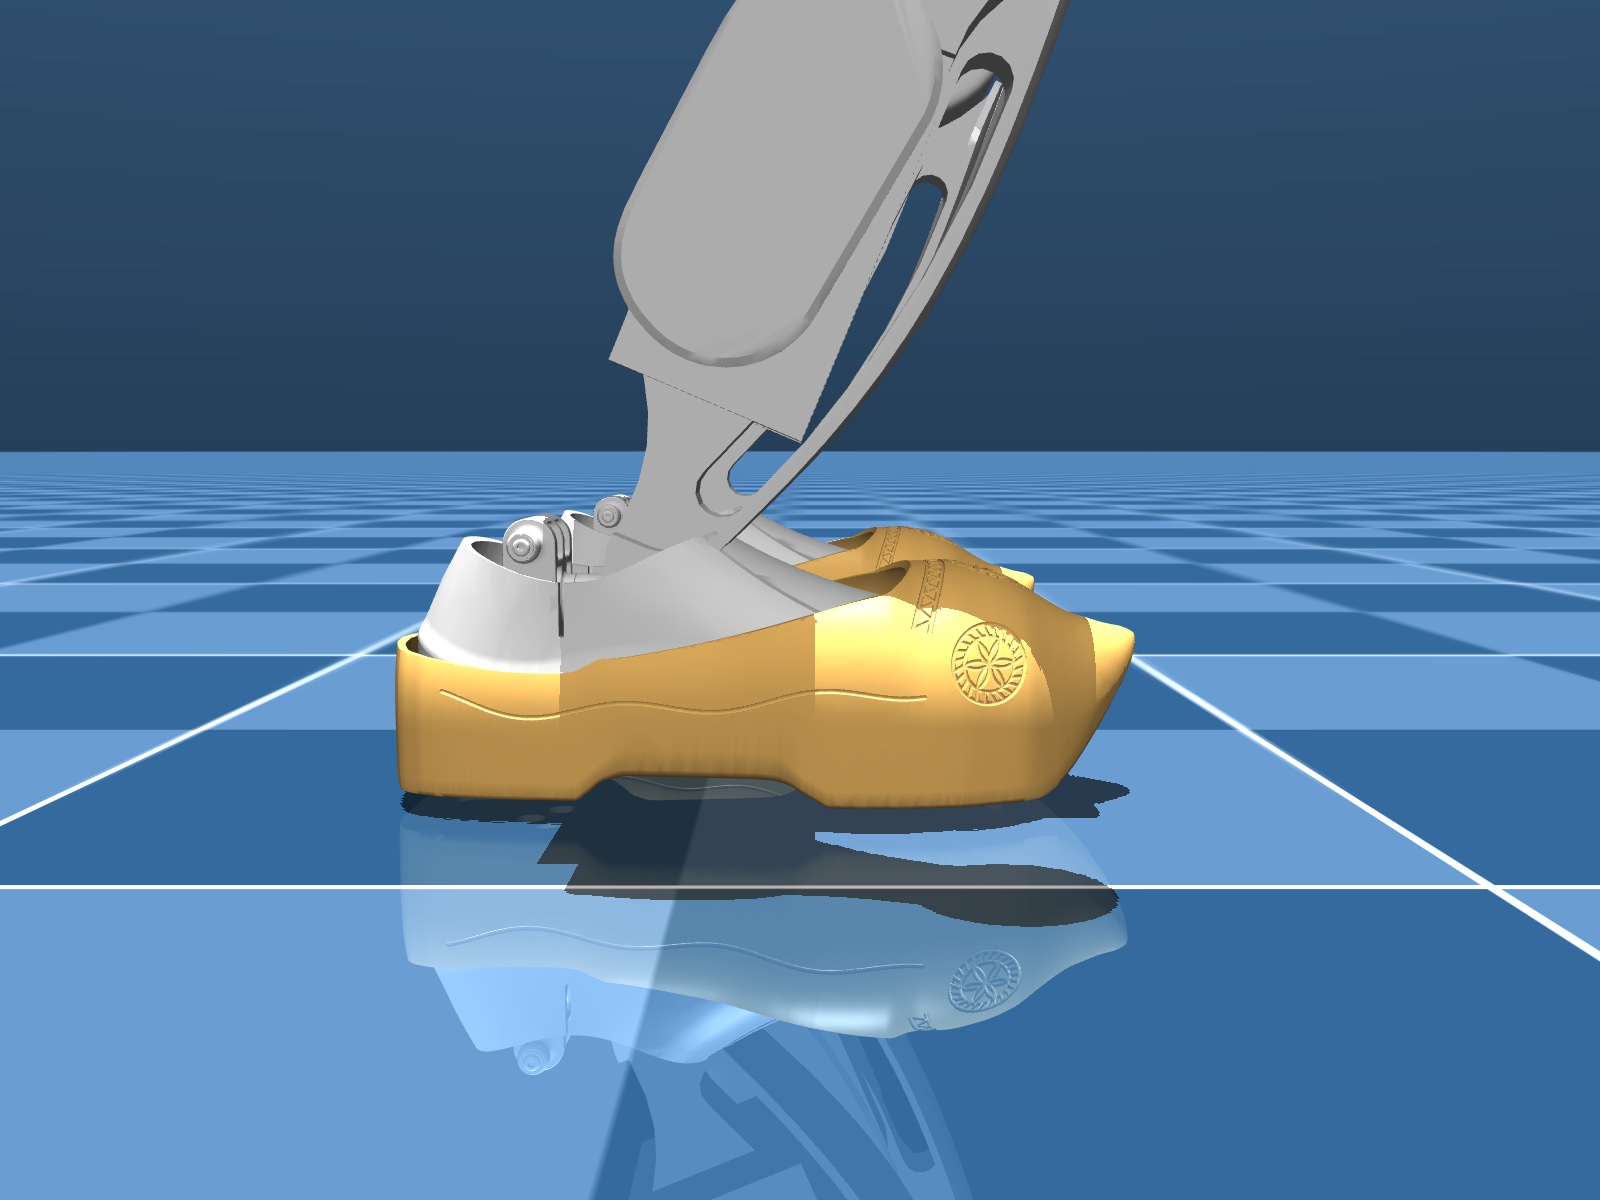
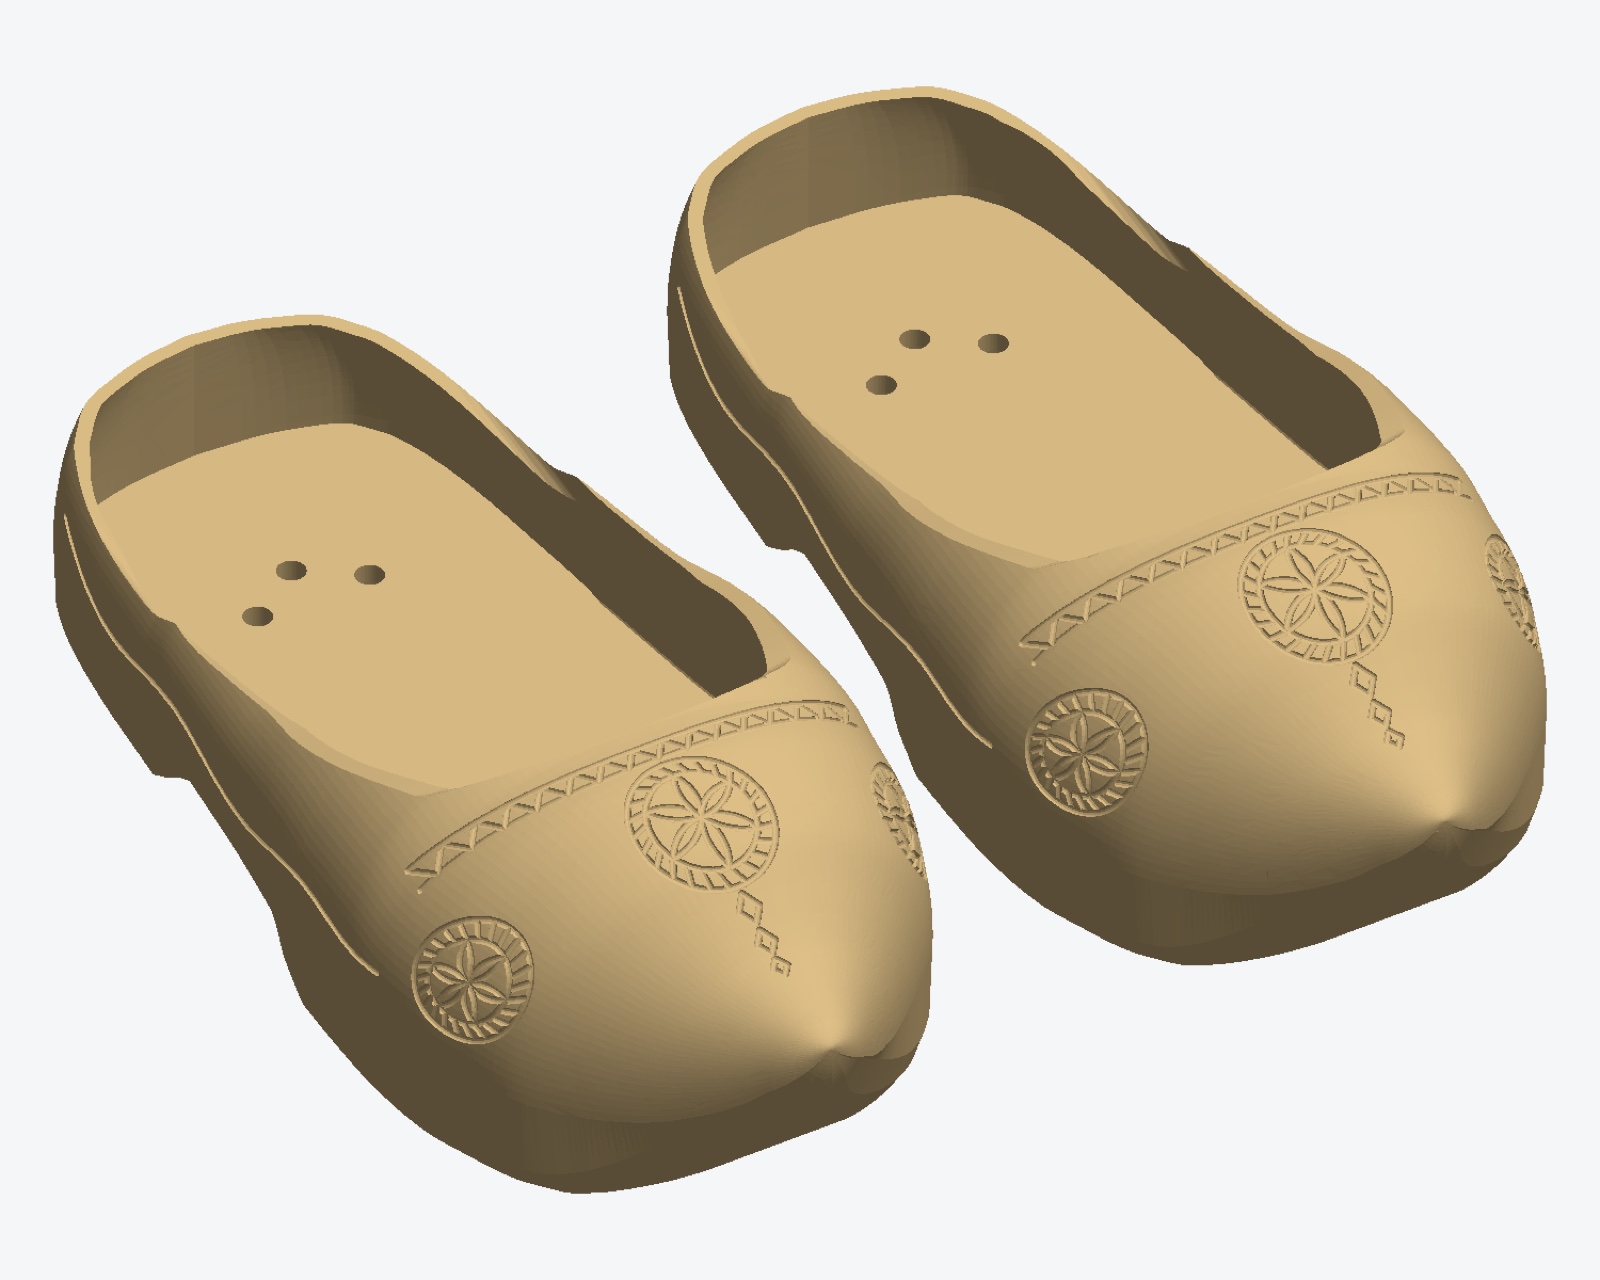
For the challenge I designed 12 types of shoes for the K1. Two were printed for the show, and both are here: solid Dutch clogs and a light open-work pair with vines. Each prints in one piece and fits over the K1’s foot.
| Size | 229 × 108 × 67 mm |
| Weight | ~350 g per shoe (estimate) |
| Robot height | +2.2 cm |
A dance policy trained barefoot also runs in the clogs in simulation without falling: body tracking error 4.94 cm, against 4.86 cm barefoot.
The files have the print STLs, the script that builds the clogs, an ornate version with a heel rosette, side tulips and a rope border, three vine versions (open-work, relief, full), and the K1 wearing them in MuJoCo and as a URDF.