kyry.me/open-source

Open source

Datasets, policy weights, code, robot models and workshop slides I have released. Each links to its project page.

Datasets

  • G1 Dances893 dances from the AIST Dance Video Database, retargeted to the Unitree G1 and tracked zero-shot by NVIDIA SONIC in simulation. 10 styles, 2.8 hours.dataset3D viewerwebsiteproject
  • K1 Dances1046 dances from the AIST Dance Video Database, retargeted to the Booster K1 and tracked zero-shot by SONIC-K1 in simulation. 10 styles, 3.1 hours.dataset3D viewerwebsiteproject
  • H2 Dances1363 dances from the AIST Dance Video Database, retargeted to the Unitree H2 with UMR. 10 styles, about 5 hours, kinematic references with per-clip quality metrics.dataset3D viewerwebsiteproject
  • K1 Moves58 clips (14 min) of dances, emotes, styled walks and karate for the Booster K1, each tracked by SONIC-K1 with no per-motion training.datasetproject
  • RFCP datasetA runway catwalk for the Unitree G1 (walk, turn, pose, walk back), in SONIC’s format.datasetproject

Policies and weights

  • SONIC-K1Open-weights whole-body motion tracker for the Booster K1, ported from NVIDIA SONIC.codeweightsproject
  • RFCP, Robot Fashion Catwalk PolicyA SONIC fine-tune that walks the Unitree G1 down a runway, turns, poses and walks back.codepolicy + ONNXproject
  • Microduck Arena LabFaster running gaits for Pollen Robotics’ Microduck on three simulated race courses.code and weightsproject

Code and hardware

  • Expressive MotionFrom a monocular runway video to a catwalk gait on the Booster K1.codecode (ATR Lab)project
  • K1 Loco-Teleop and heel walkingA legs-only walking policy for the Booster K1 that leaves the arms free for teleoperation, and walking in heel shoes.codeproject
  • K1 Shoes3D-printable heels, Dutch clogs and a vine pair for the Booster K1, with MuJoCo models.heel filesclog and vine filesproject
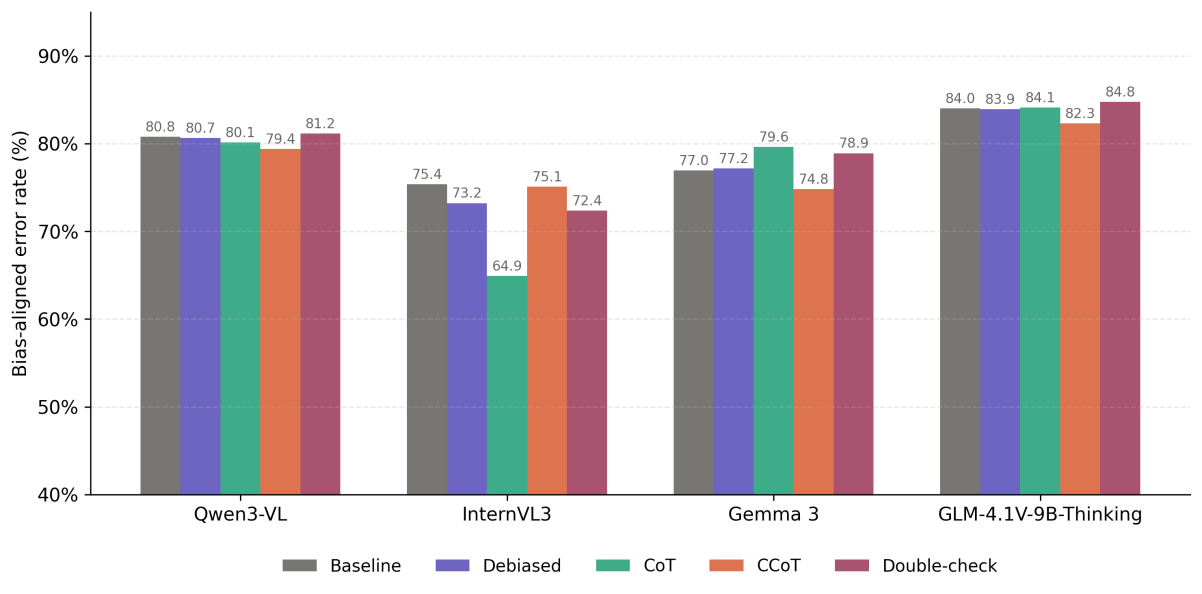
  • Structured prompting and knowledge bias in VLMsCode and results: four open-source VLMs, five prompting strategies, the VLMBias benchmark.codeproject

Workshops

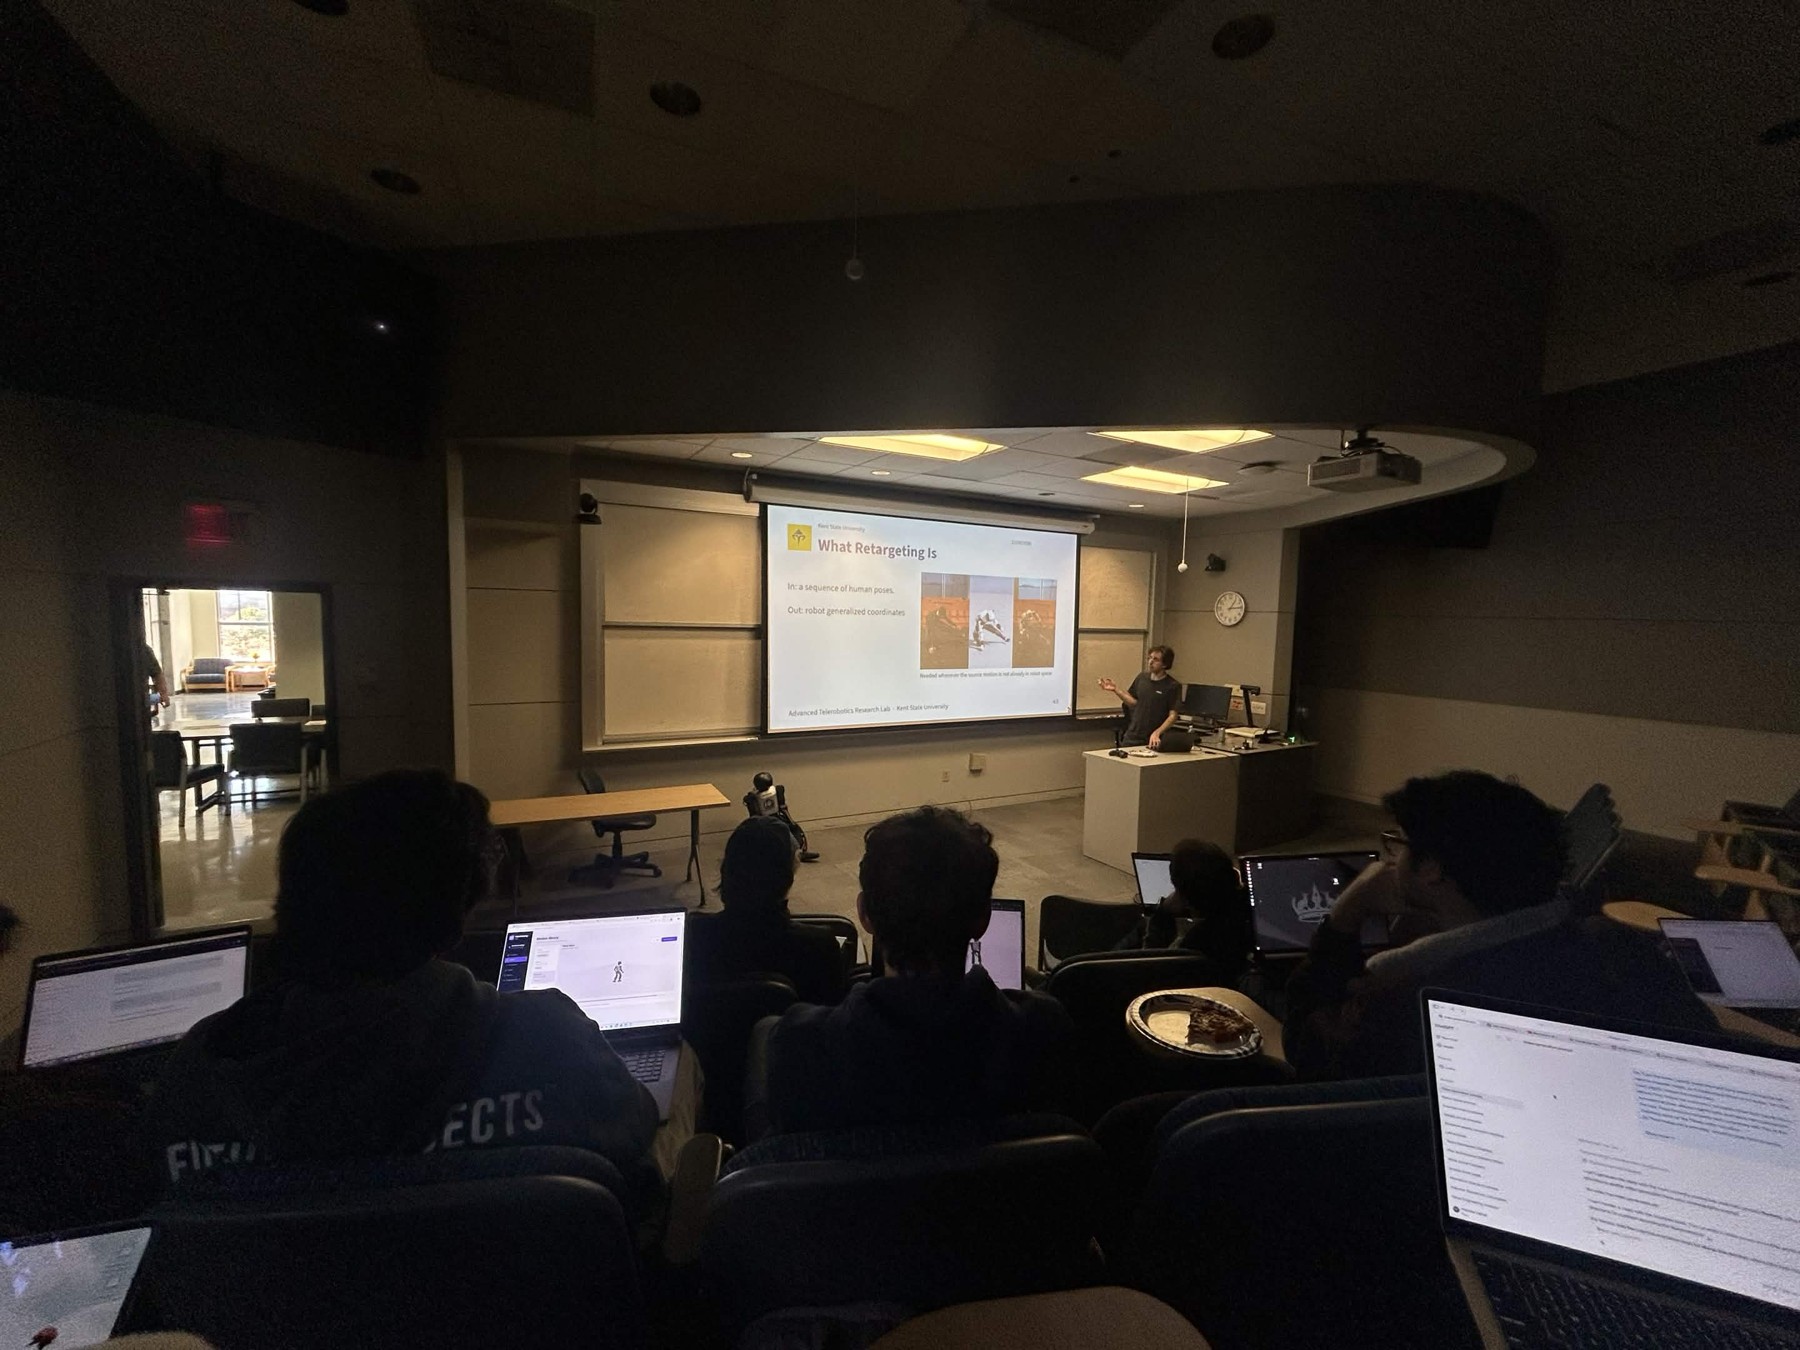
  • Humanoid robot learning workshopsSlides from my workshops at Kent State, for the ATR Lab and the whole university: humanoid motion training (84 slides) and reinforcement learning for humanoids (49 slides).motion training slidesRL slidesproject

Robot models and guides

  • Unitree G1 USD for Isaac LabThe G1 exactly as NVIDIA SONIC uses it, ready to load without URDF conversion.model
  • Booster K1 USD for Isaac LabThe K1 exactly as SONIC-K1 uses it, ready to load without URDF conversion.model
  • Isaac Lab on H100Training Isaac Lab 2.x policies headless on H100 GPUs: what works and which errors are harmless.guidecode